Internship · Project Lead
Autonomous Manufacturing Studio
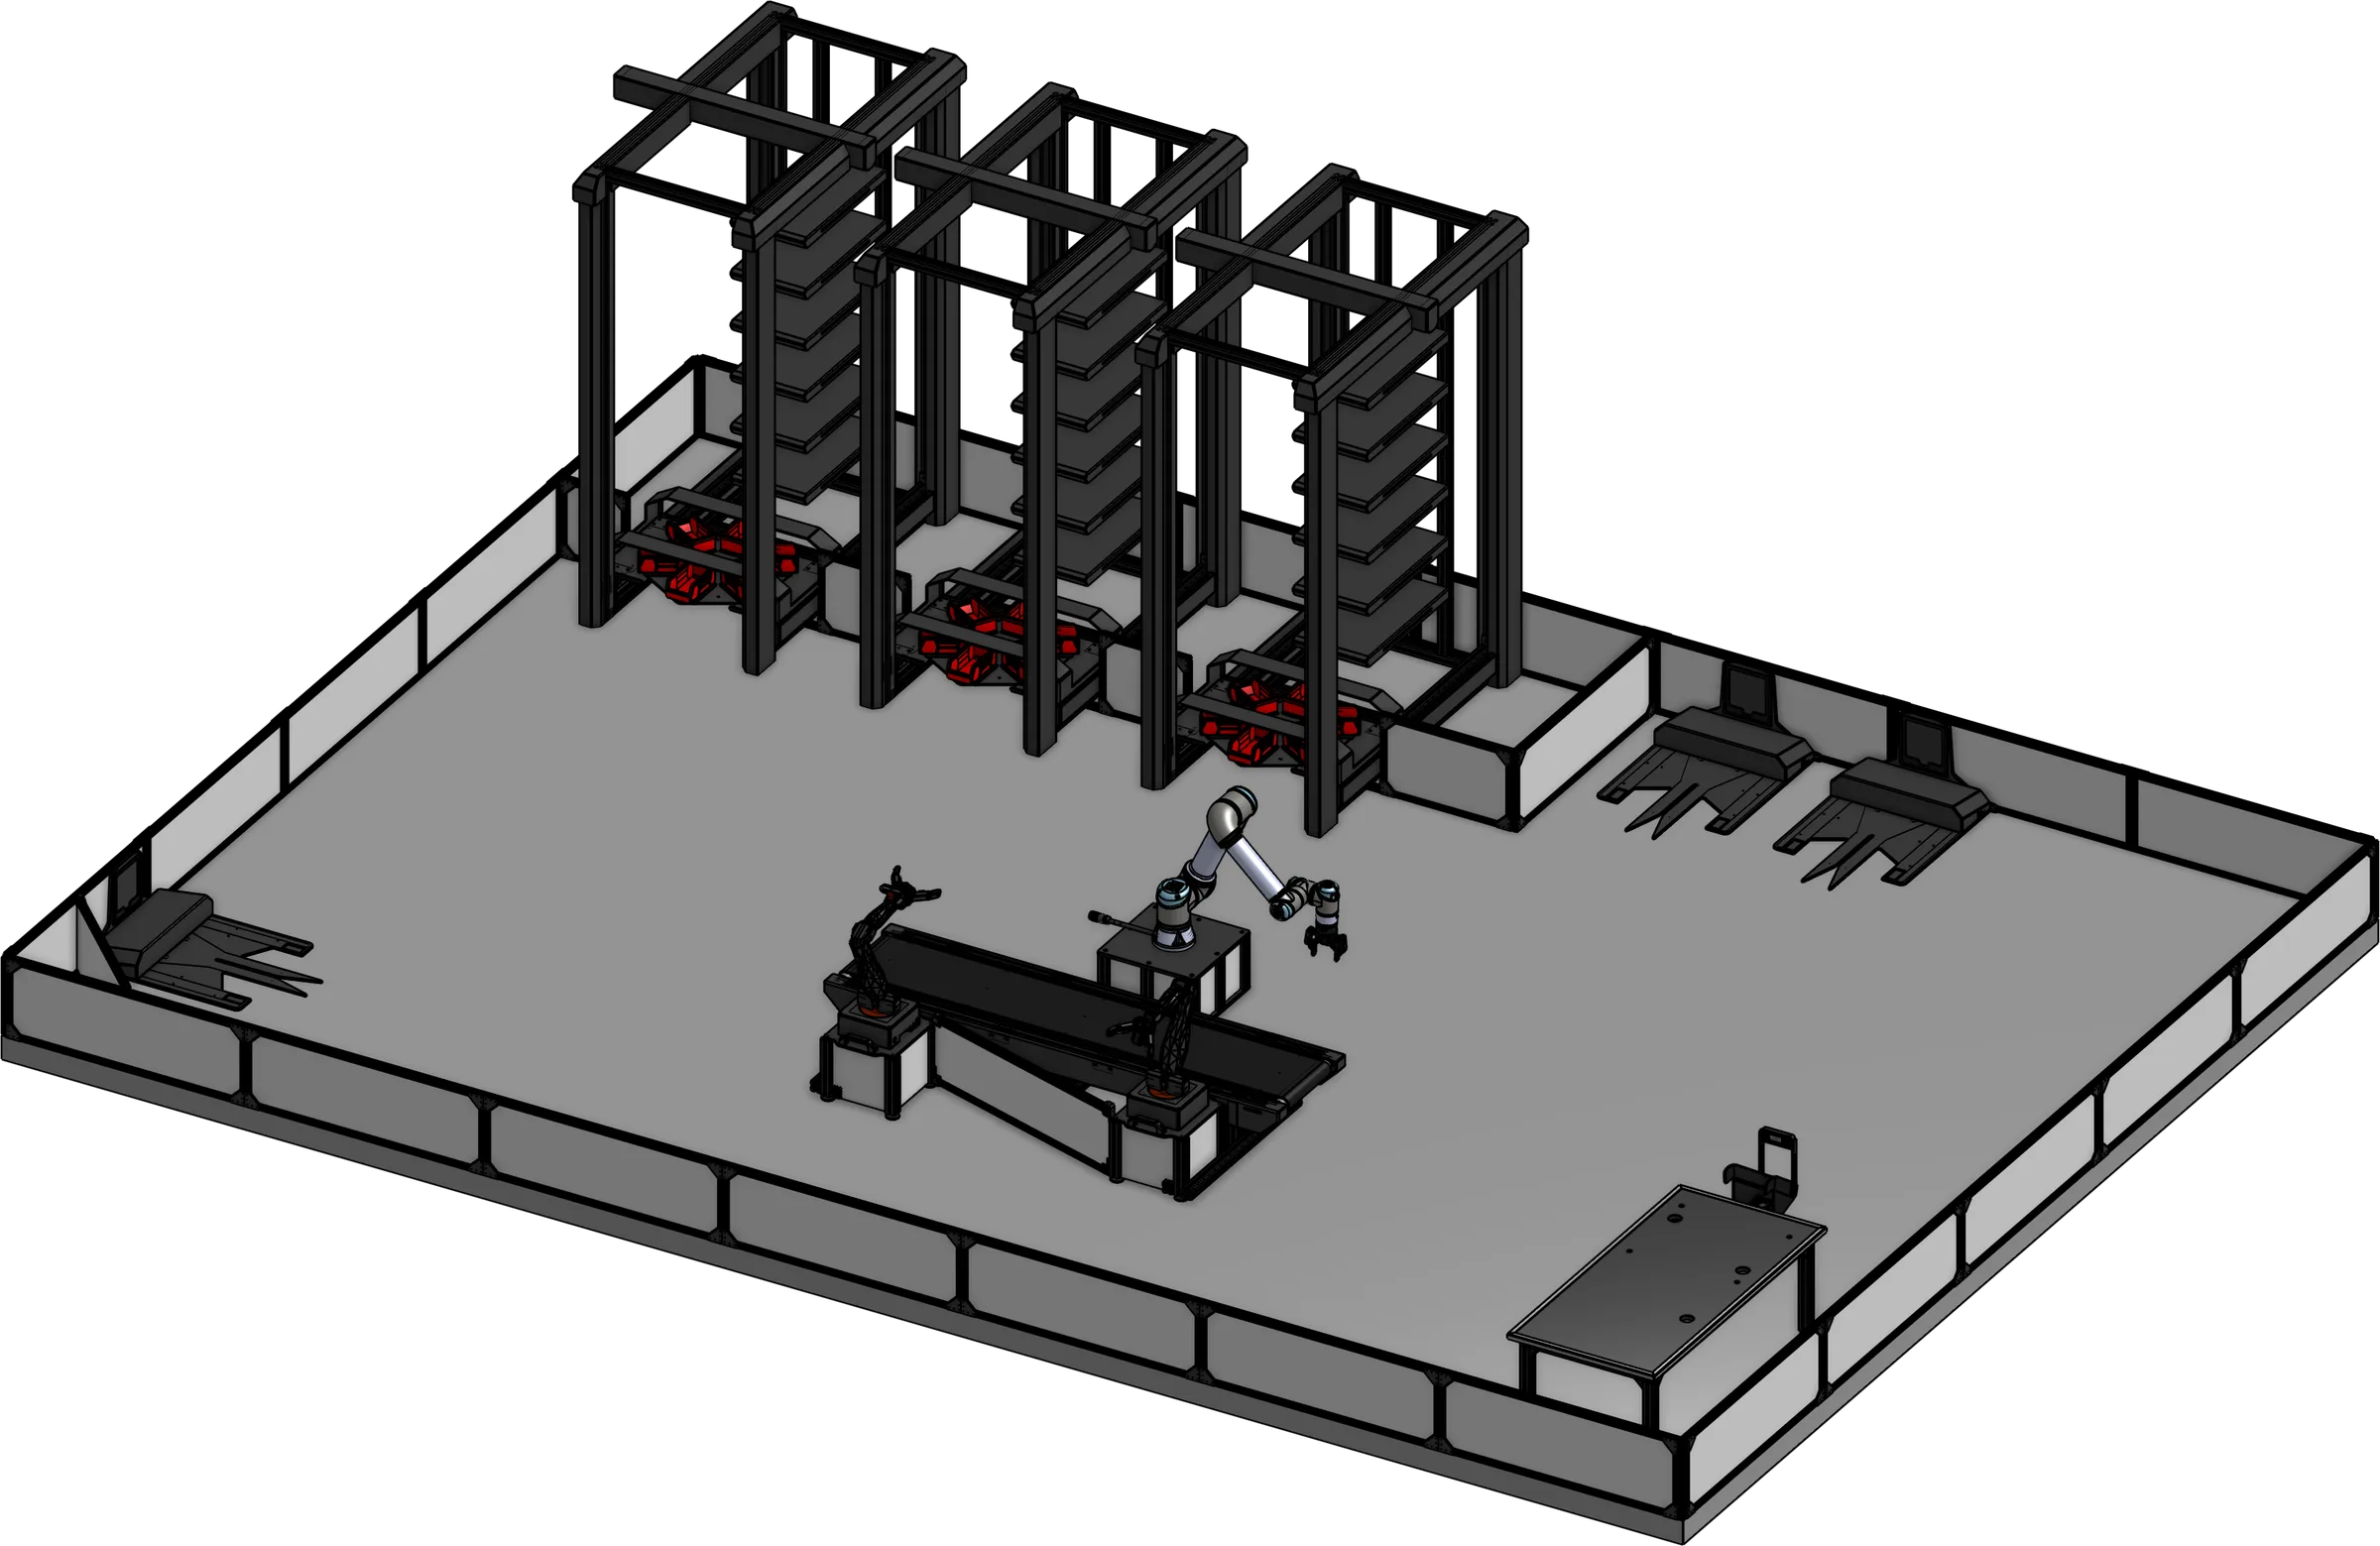
I lead development of the control system software for CBU's Autonomous Manufacturing Studio. It coordinates automated movement across a fleet of six autonomous mobile robots (AMRs), a 6DOF Universal Robots UR5e arm and three 4DOF Quanser QArms. Custom web servers and visualization interfaces give overhead control of 10+ factory endpoints, with filtered localization from LiDAR, odometry, AI vision and motion capture.
This page is still in development, more details coming soon