Cal Baptist Long Knights VEXU
I've worked in all three of the team's divisions:
- 2024/25 · High StakesSoftware
- 2025/26 · Push BackElectronics: Responsible Engineer
- 2026/27 · OverrideMechanical

Override season robot reveal: December 2026
Push Back was my second season with the team and my second trip to the VEX World Championship. It’s a highly competitive game where no block is permanently scored: teams fight to keep their own colors in the goals while sliding the opposing color out. We finished #1 in California and #20 in the world in Skills.
Autonomous Path Following
VEX U matches start with 30 seconds of autonomous movement, followed by 90 seconds of driver control, against another team’s two robots. We also compete in 60-second Skills runs, scoring as many points as we can autonomously with no opponent on the field.
During the autonomous portion, the robots follow spline paths across the field, localizing with onboard optical odometry sensors that track the floor as it moves past. Our robots ran an H-drive: a tank-style drivetrain with added strafe wheels for some sideways movement.
I worked on the PID controllers and pure pursuit pathing to keep the robots following their splines. I also helped build a model that anticipates braking distance and intensity, to minimize micro-tipping that would distort the optical sensor readings.
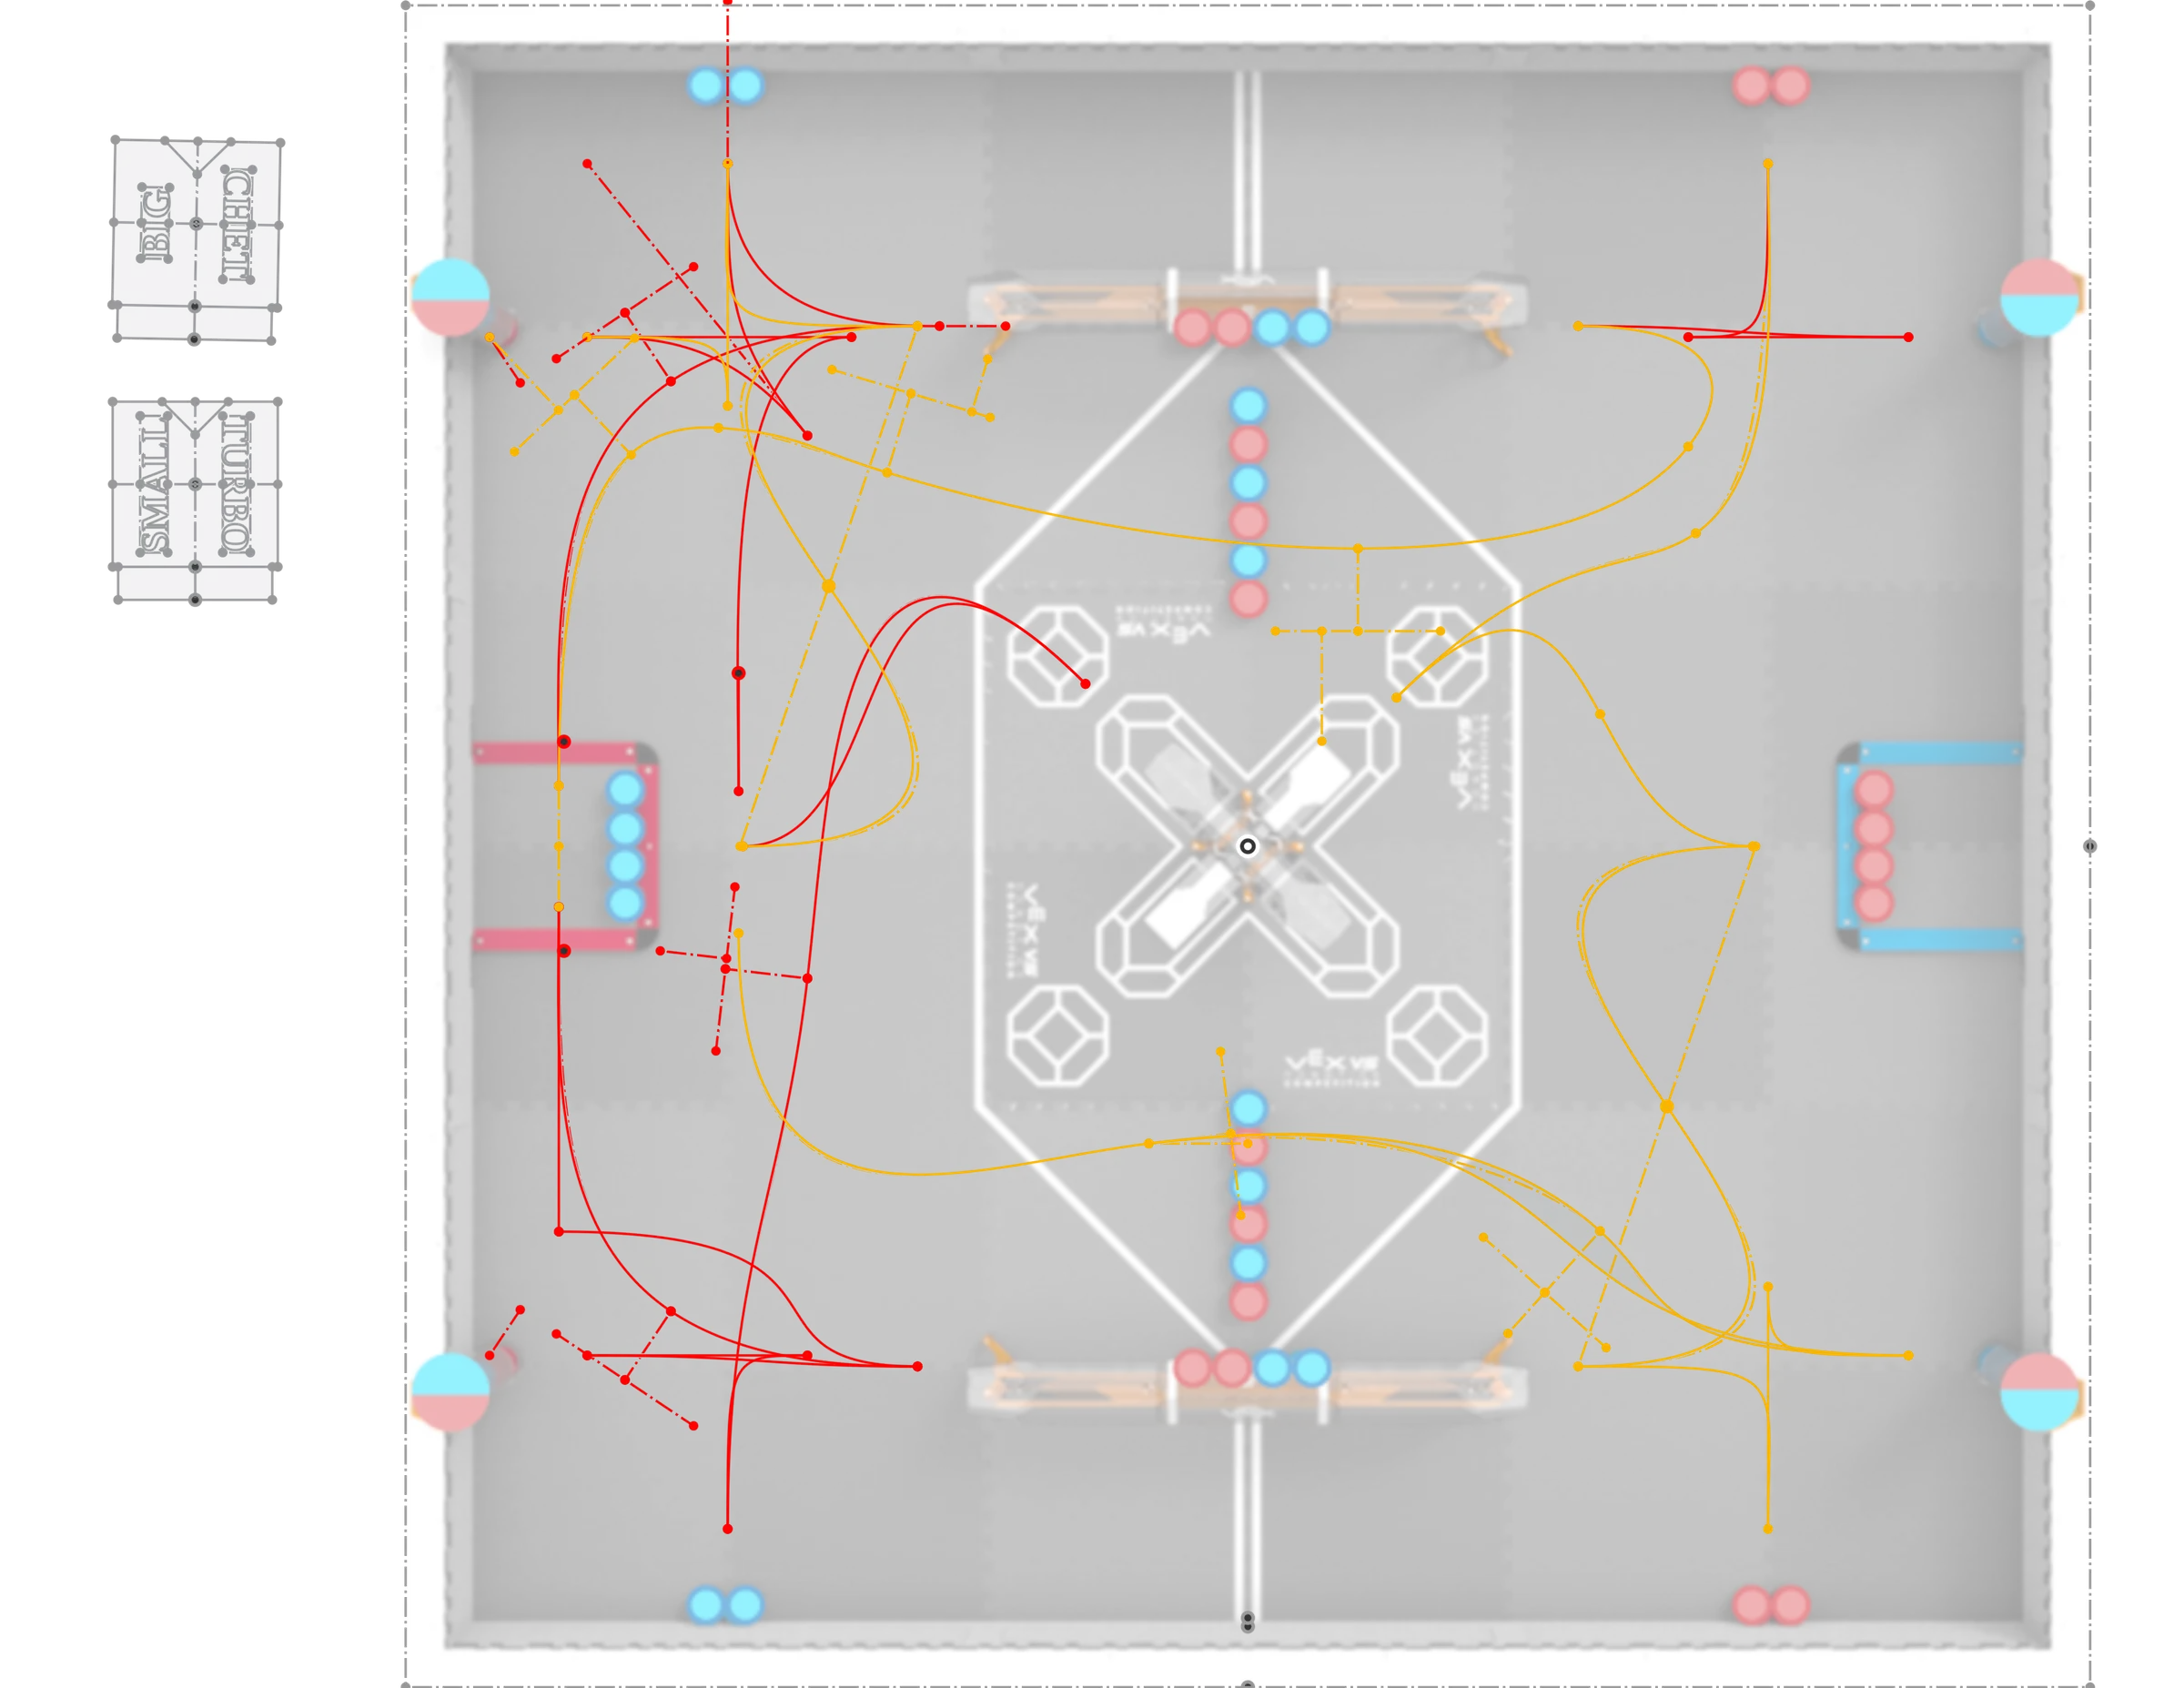
Testing footage of autonomous programs still in development
Driver Feedback Unit (DFU)
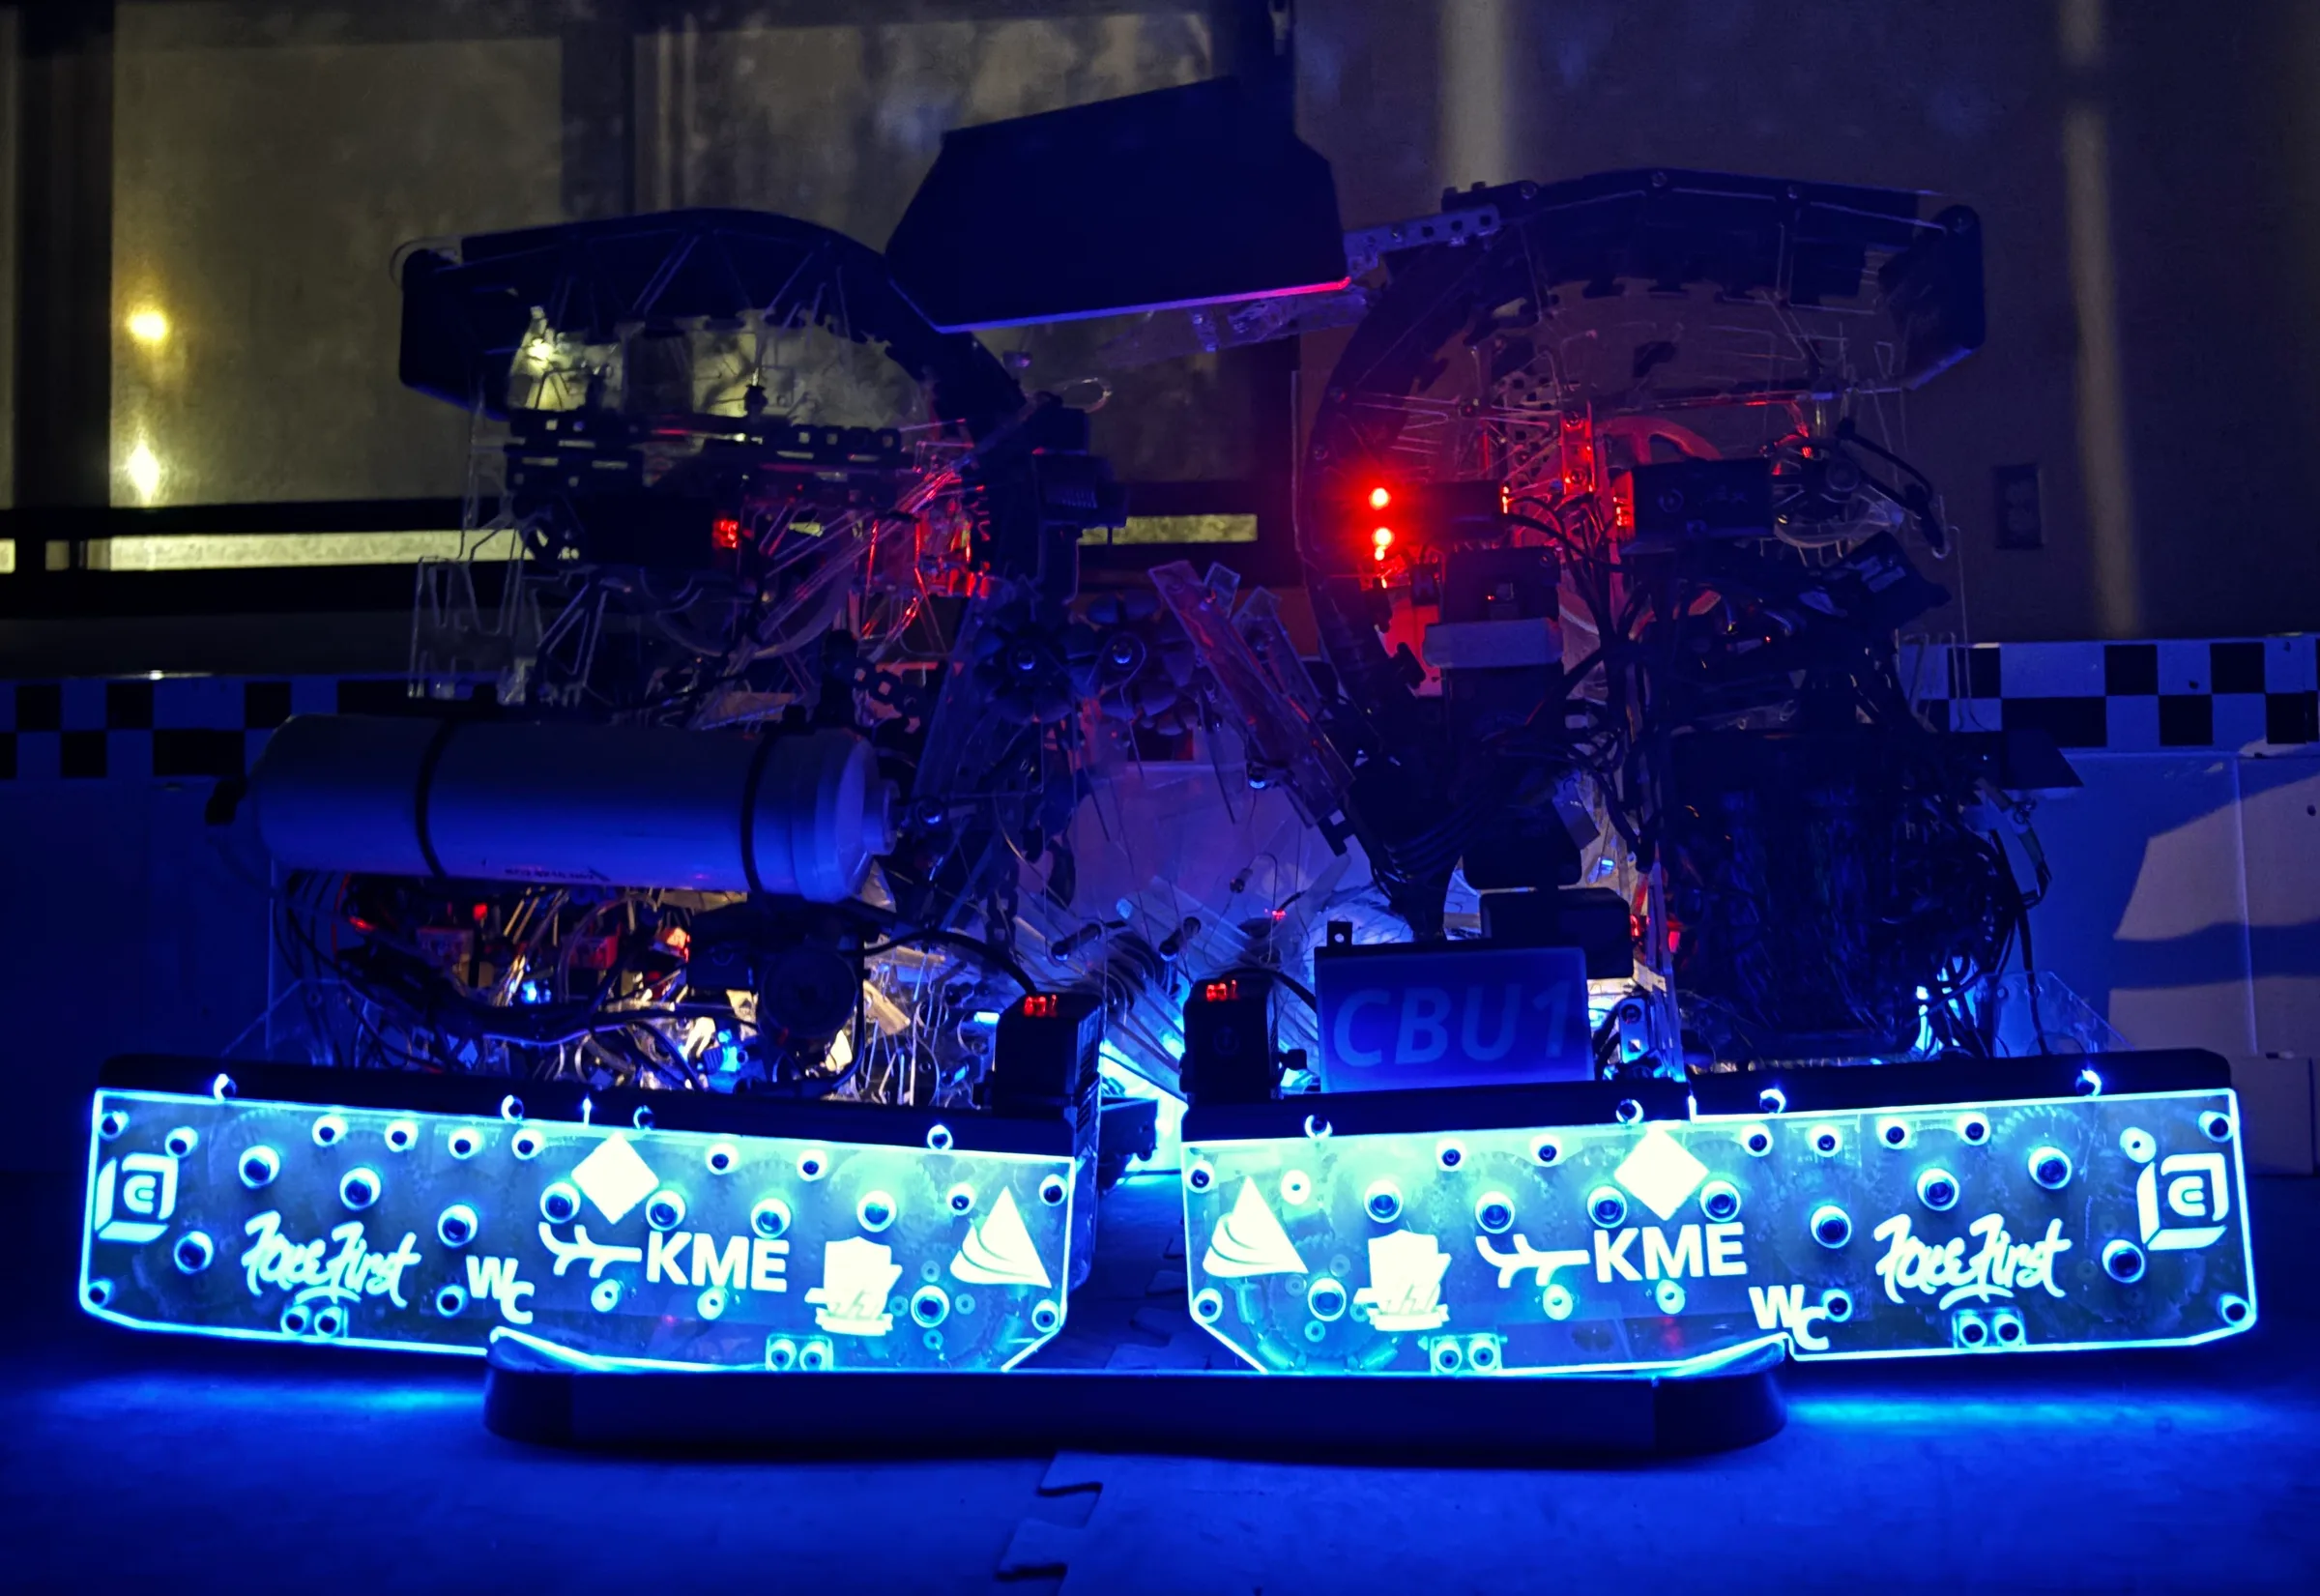
I manufactured and programmed the robot’s Driver Feedback Unit (DFU), an ESP32-S3 that drives the indicator LED strips on the outside of the robot. It sits on the same RS-485 network as the rest of the electronics, so the lights reflect the robot’s state, fetched from the V5 Brain.
The DFU also doubles as the team’s Debugger module. The Debugger relays critical robot data from the V5 Brain to our computers over ESP-NOW, via a second ESP32-S3 receiver plugged into the computer.
The DFU runs the second version of the lighting engine, which layers simple nodes (colors, fades, pulses) into status effects at 60 Hz, with the RS-485 link on one core and lighting on the other.
Electronics and Lighting Housings
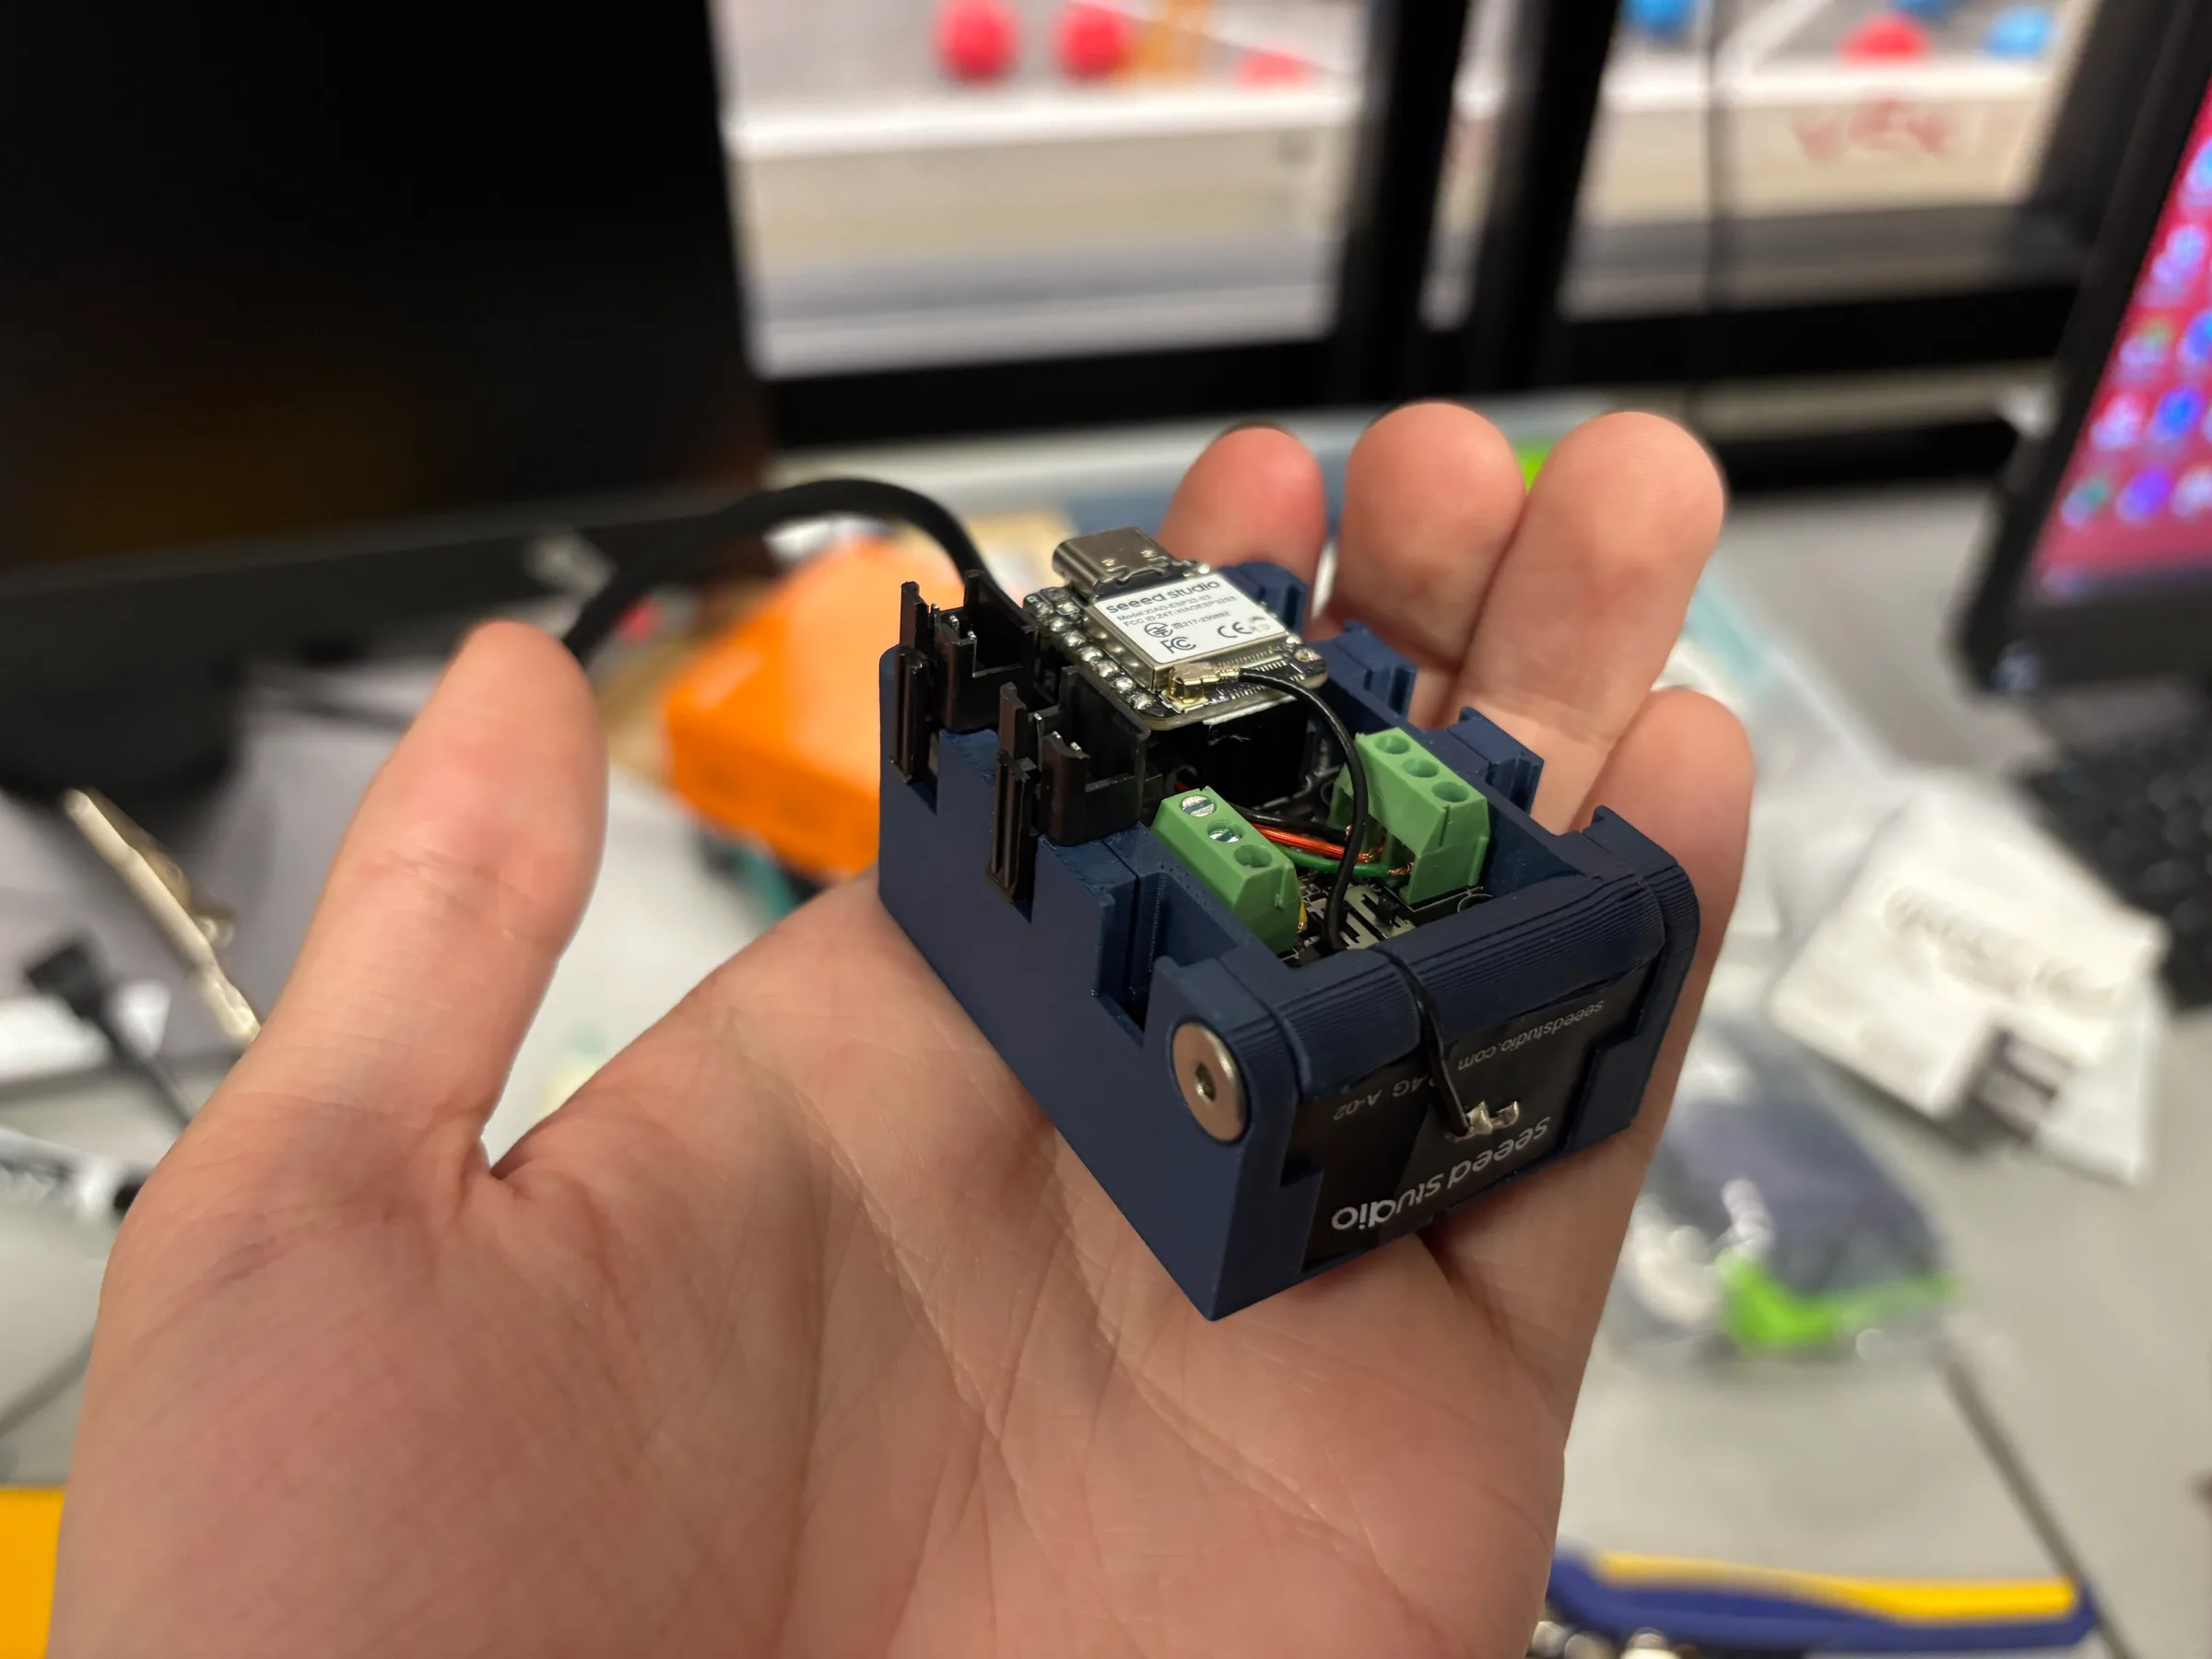
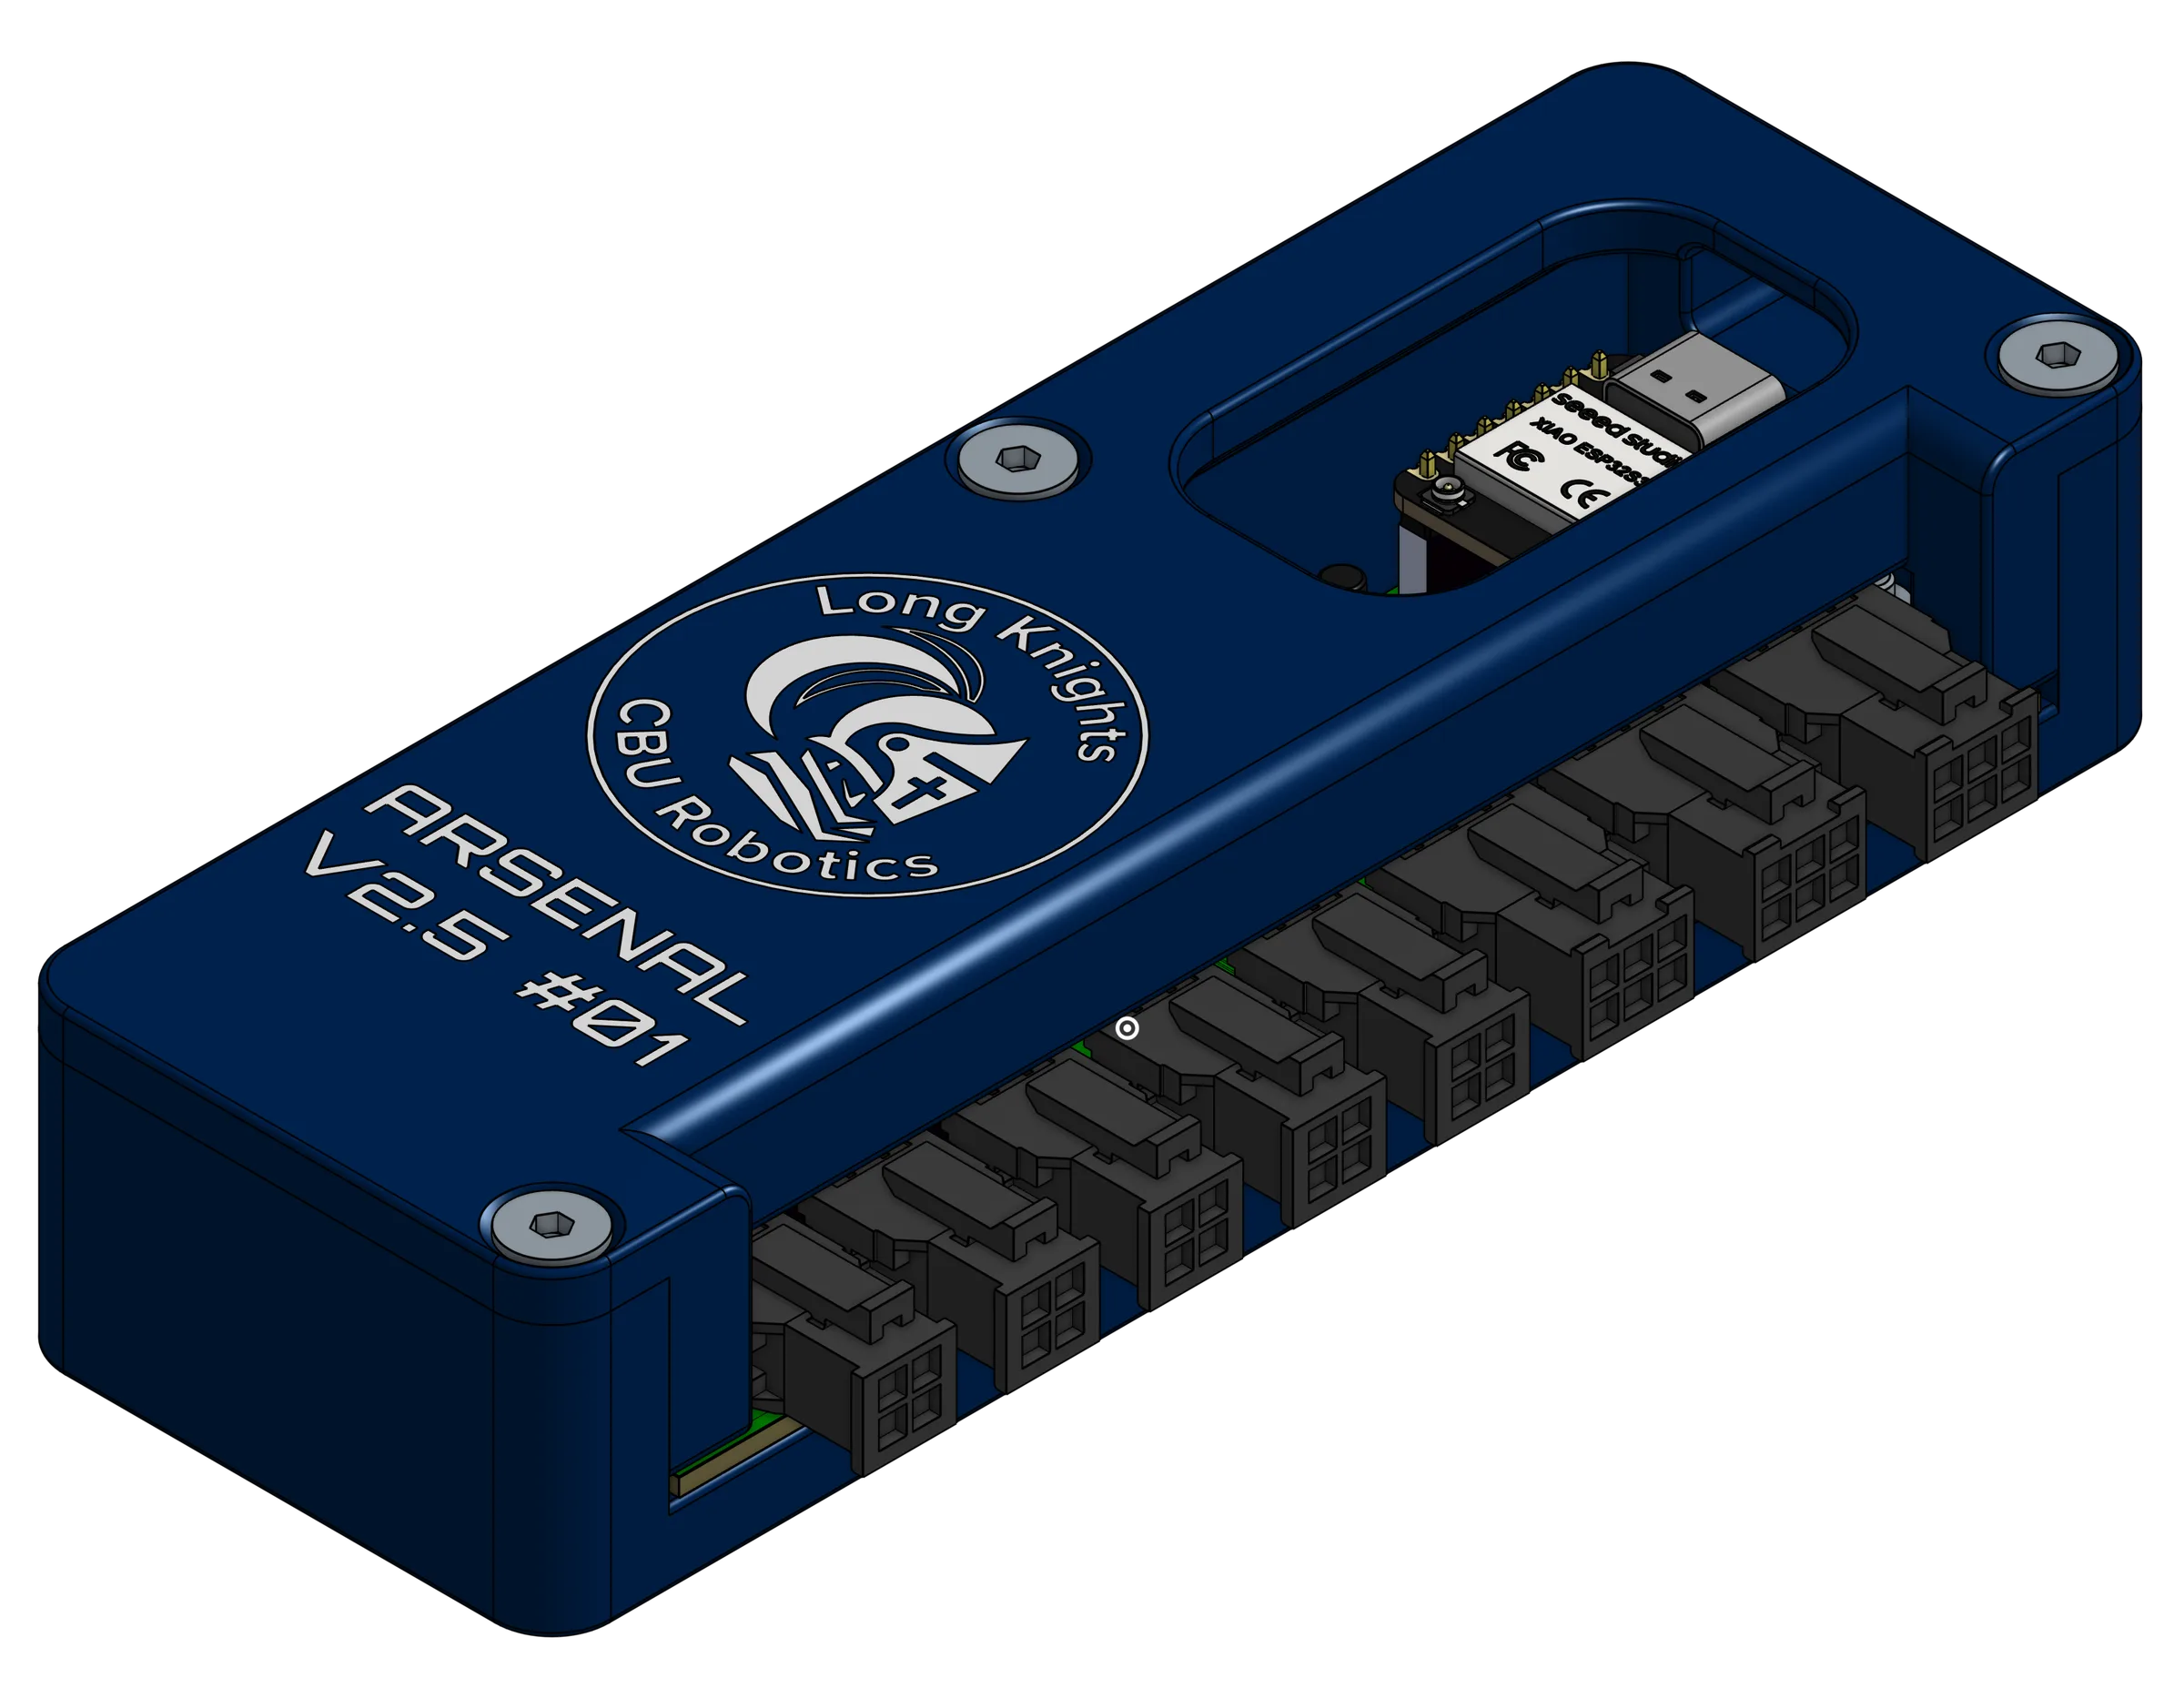
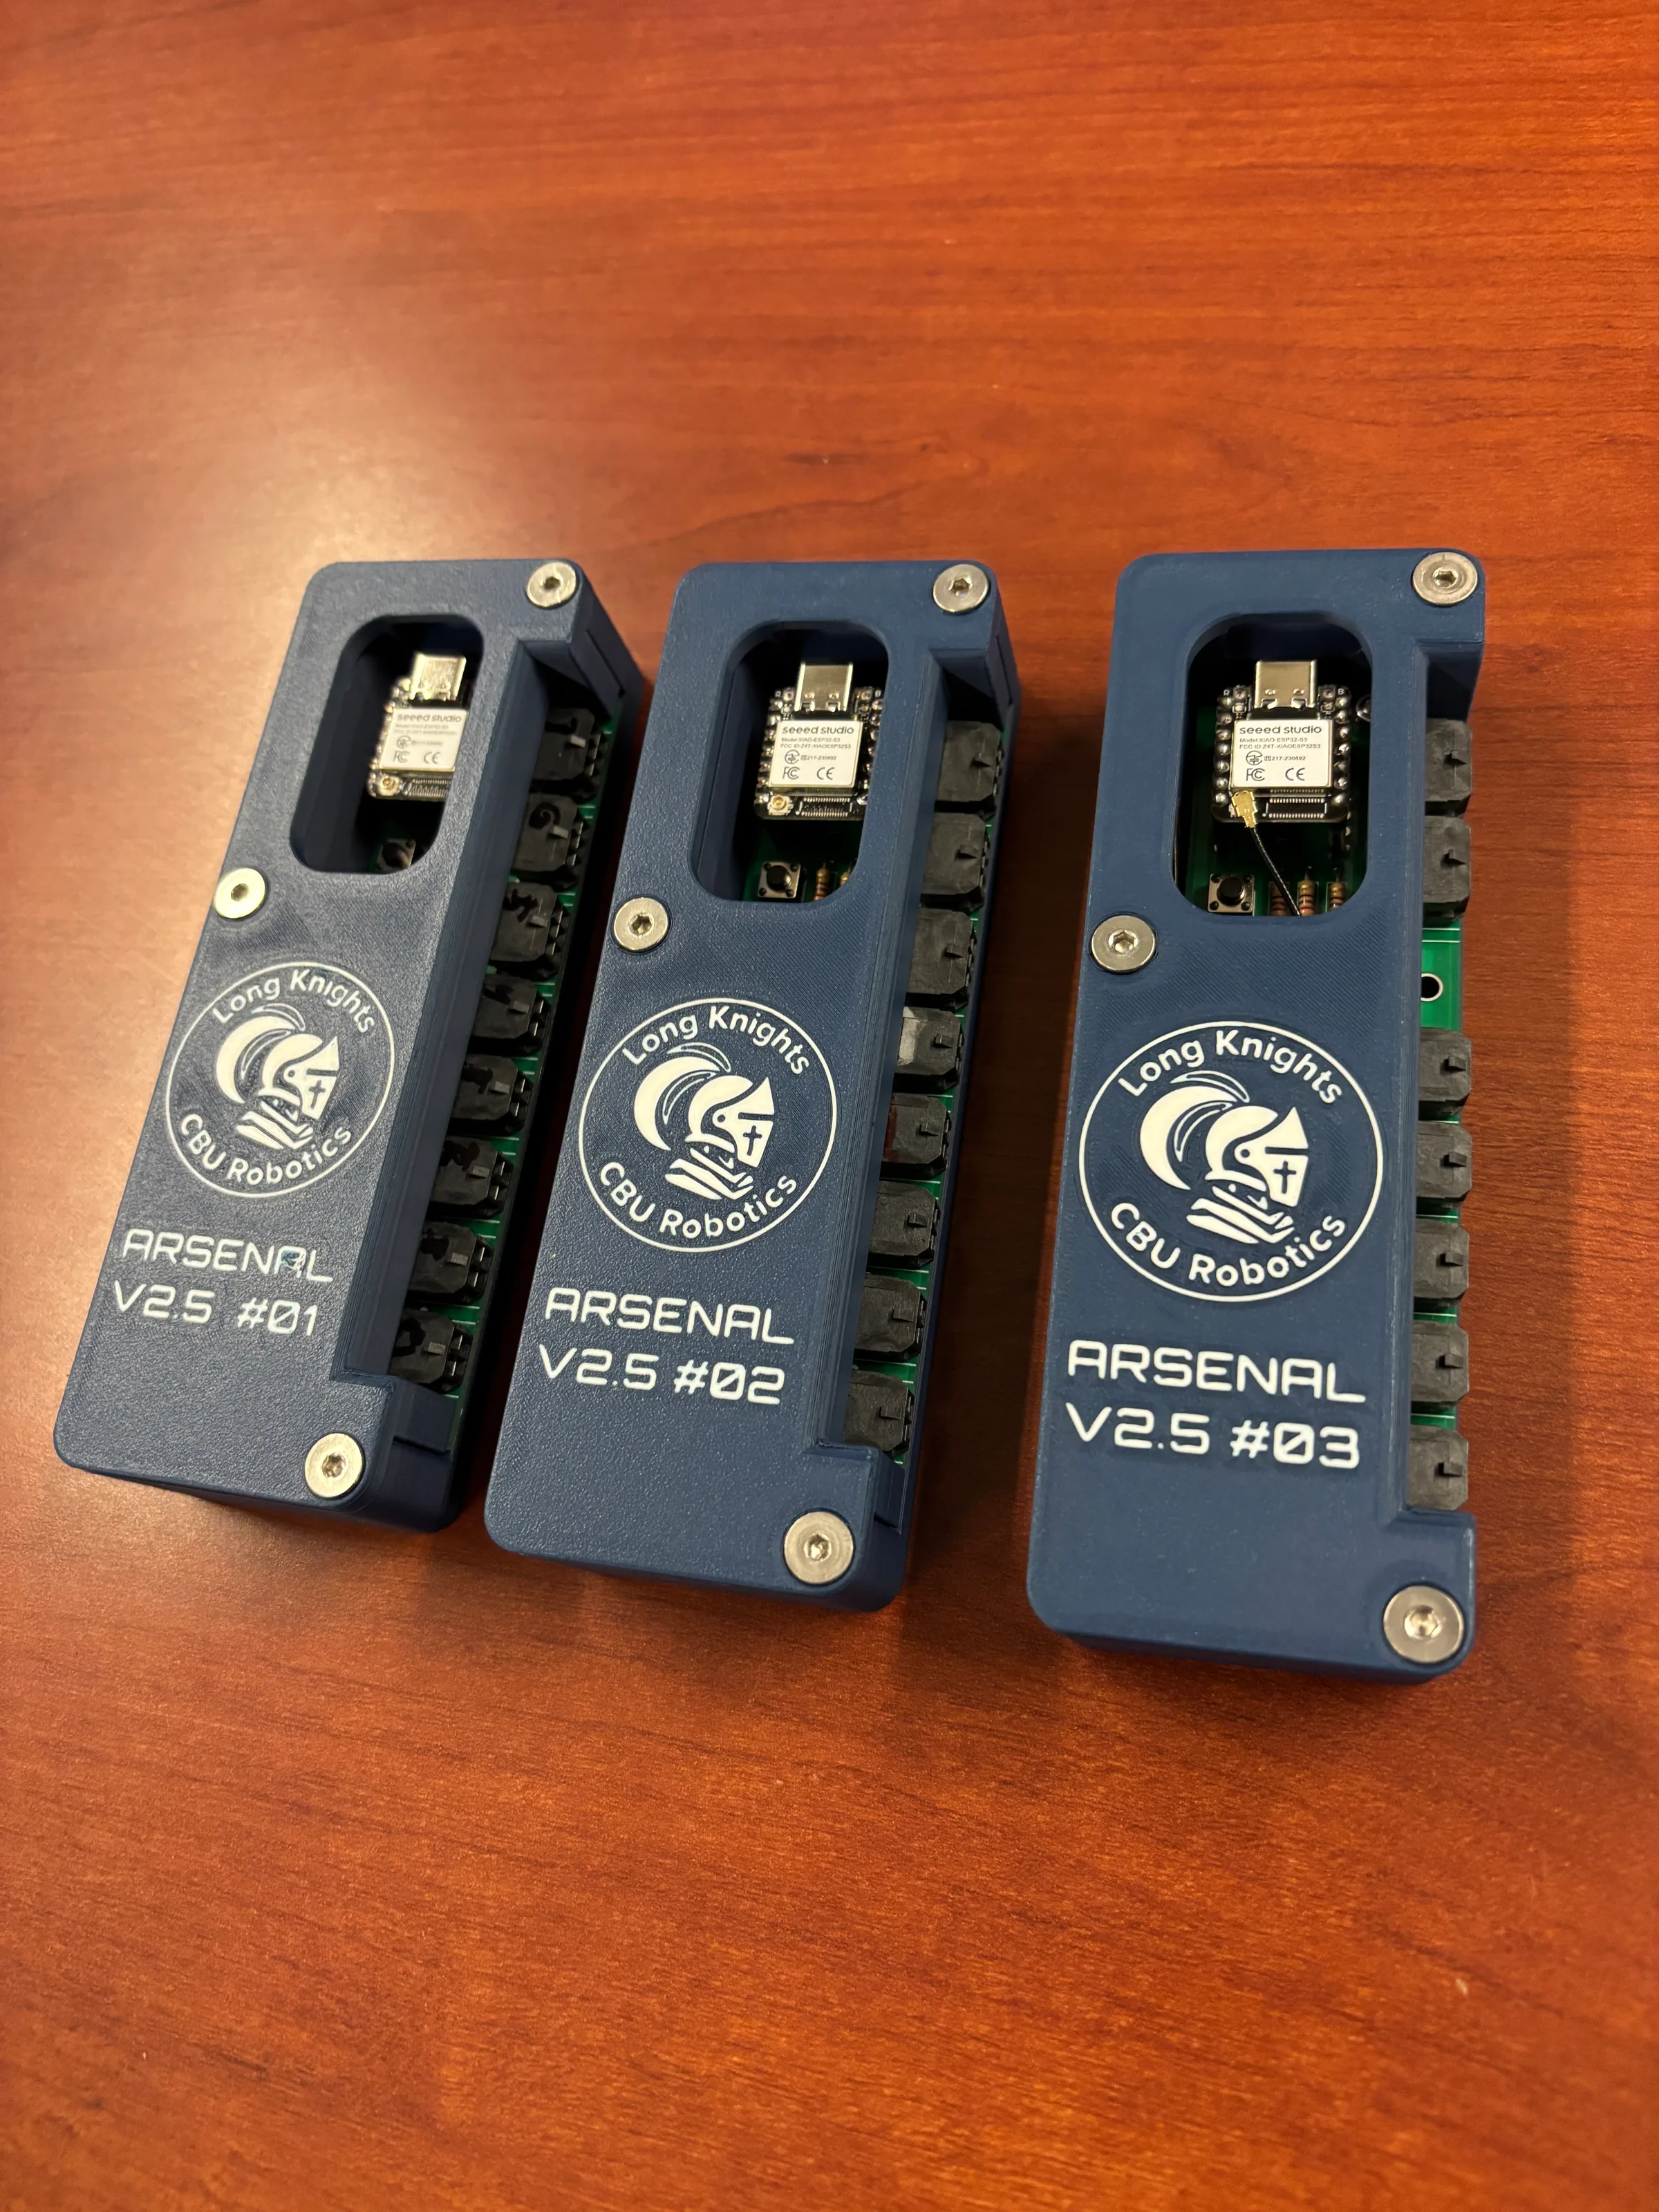
I CADded the 3D-printed housing for ARSENAL V2, the electronics team’s sensor controller board. The team needed a housing tough enough to protect the custom PCB from frequent impacts with other robots, while keeping it accessible for plugging in cables and reprogramming the ESP32-S3 controller.
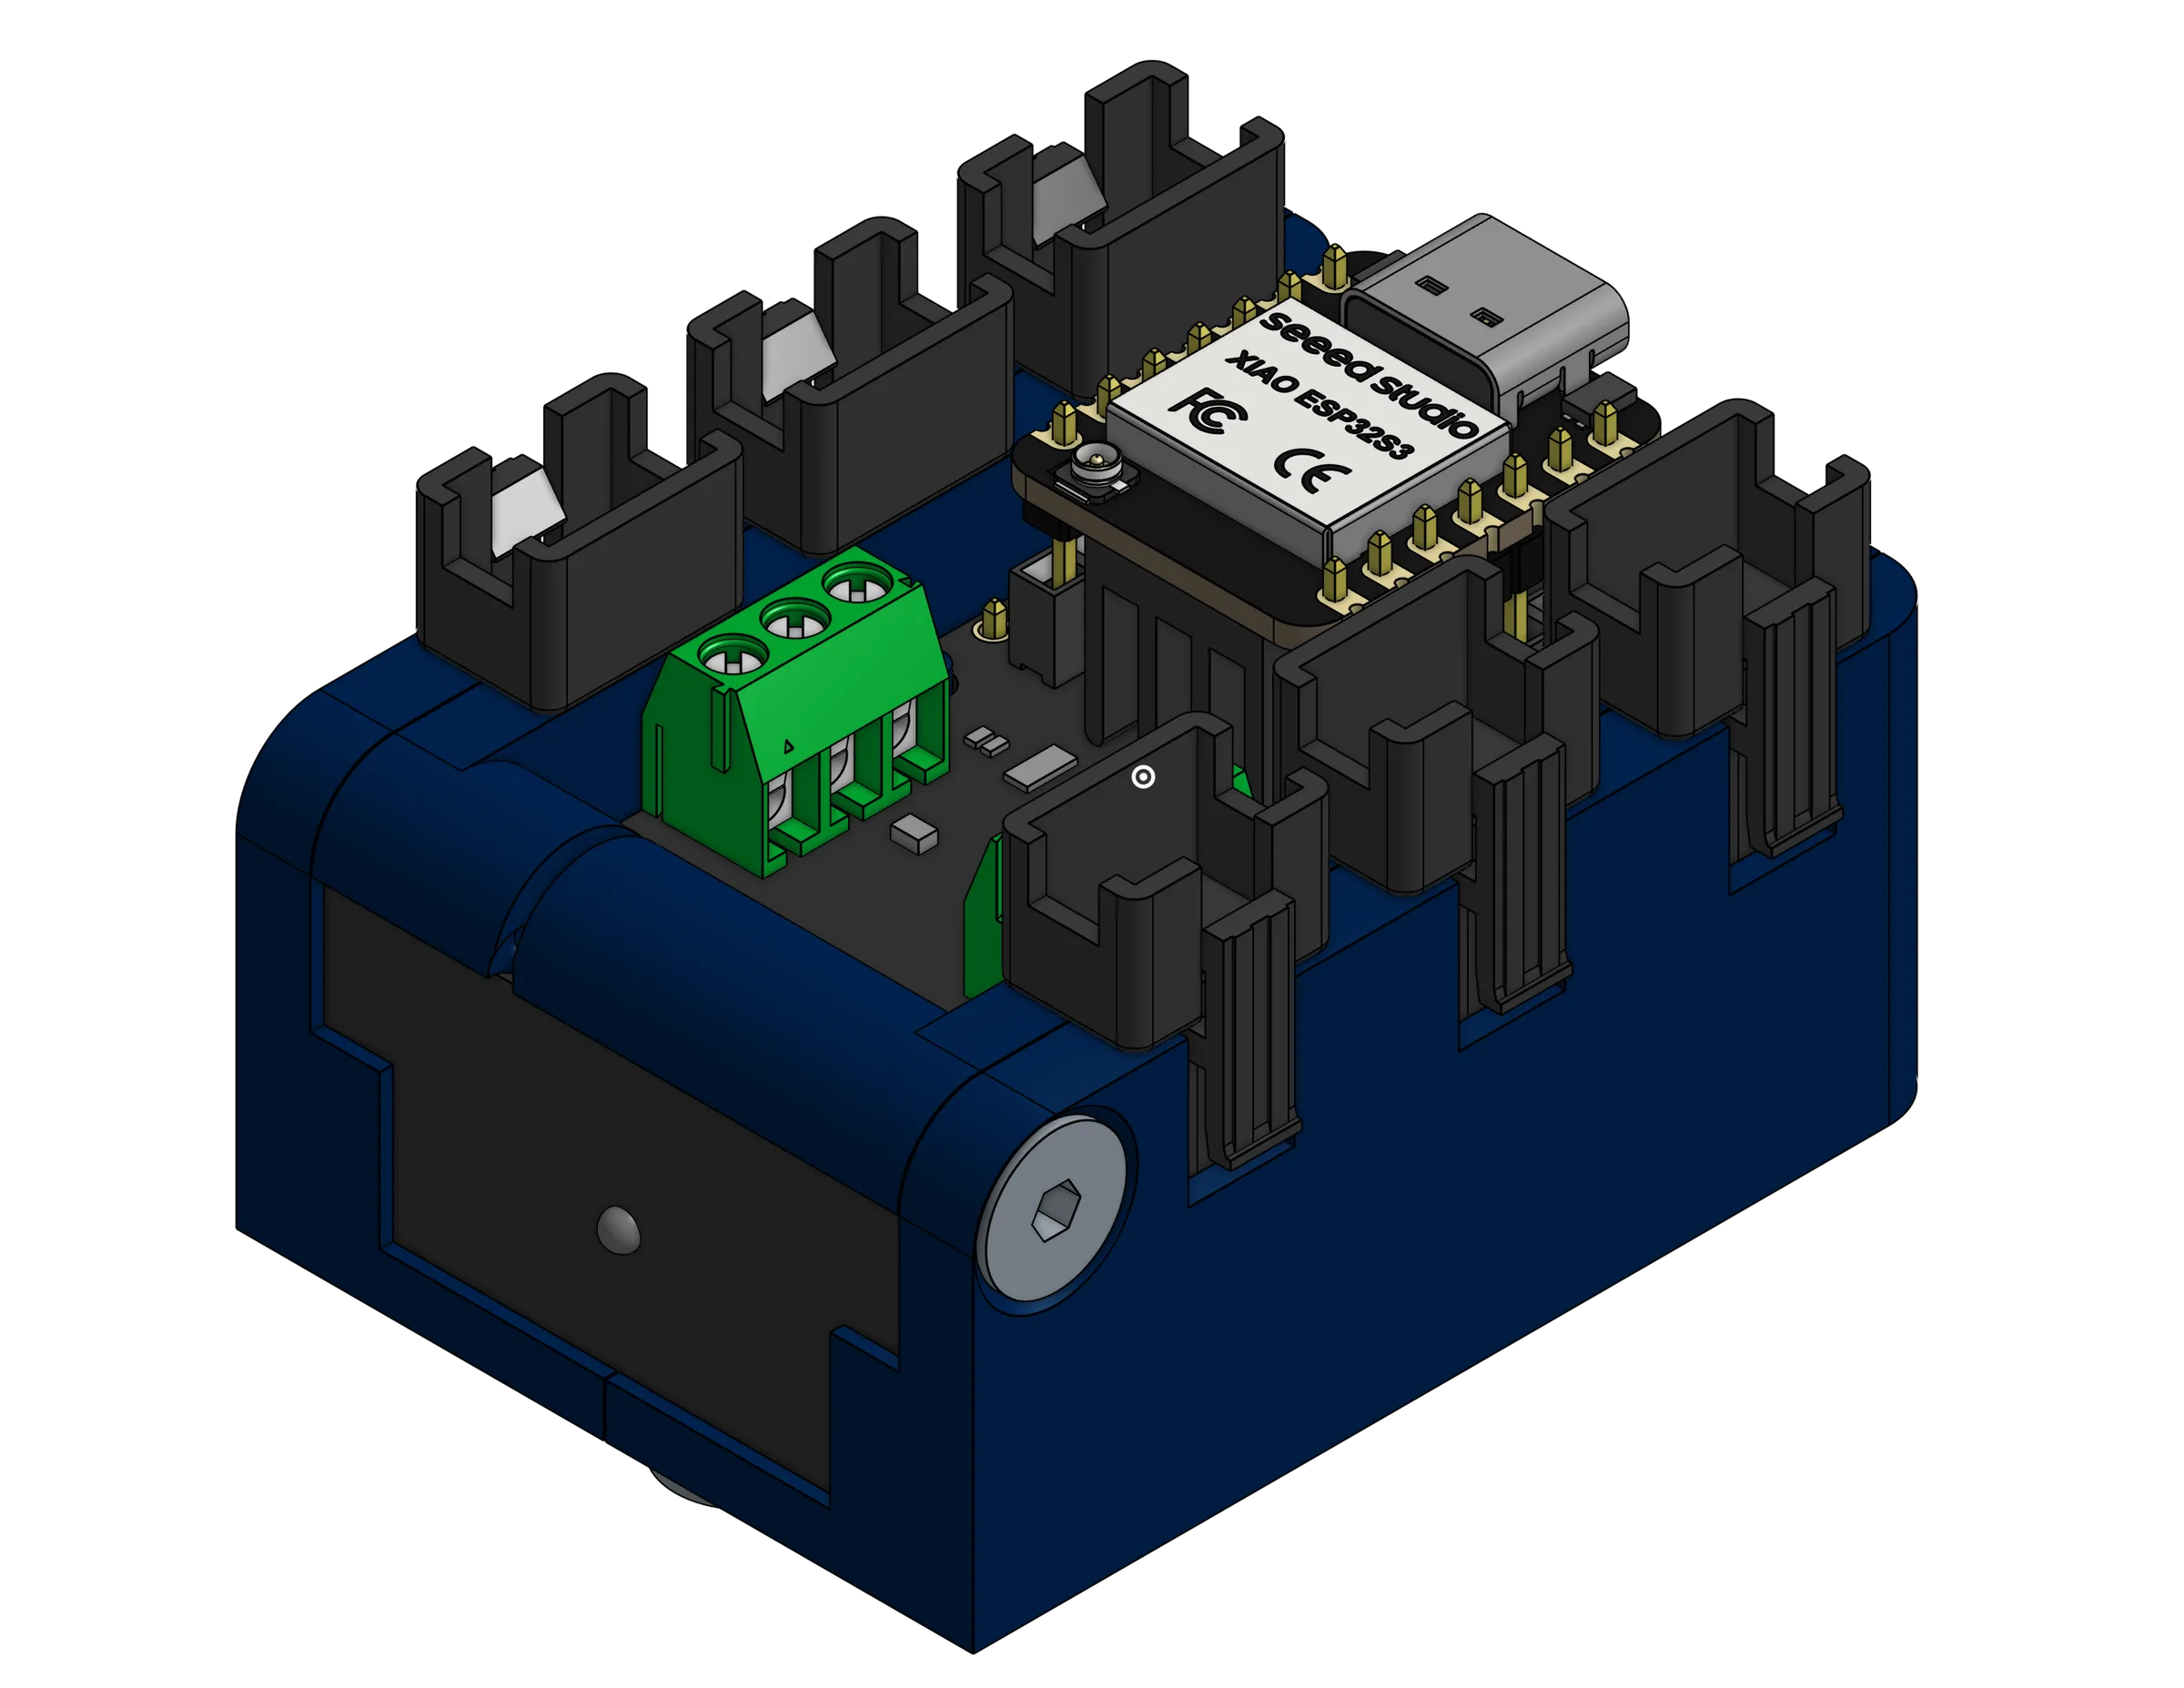
The Driver Feedback Unit needed a similar case. It looks simple from the outside, but it encloses a suspended breadboard underneath the ESP32-S3 and RS-485 hat. Inside, it leaves room for the wiring to six JST connectors, with detachable pins and connectors for easy assembly.
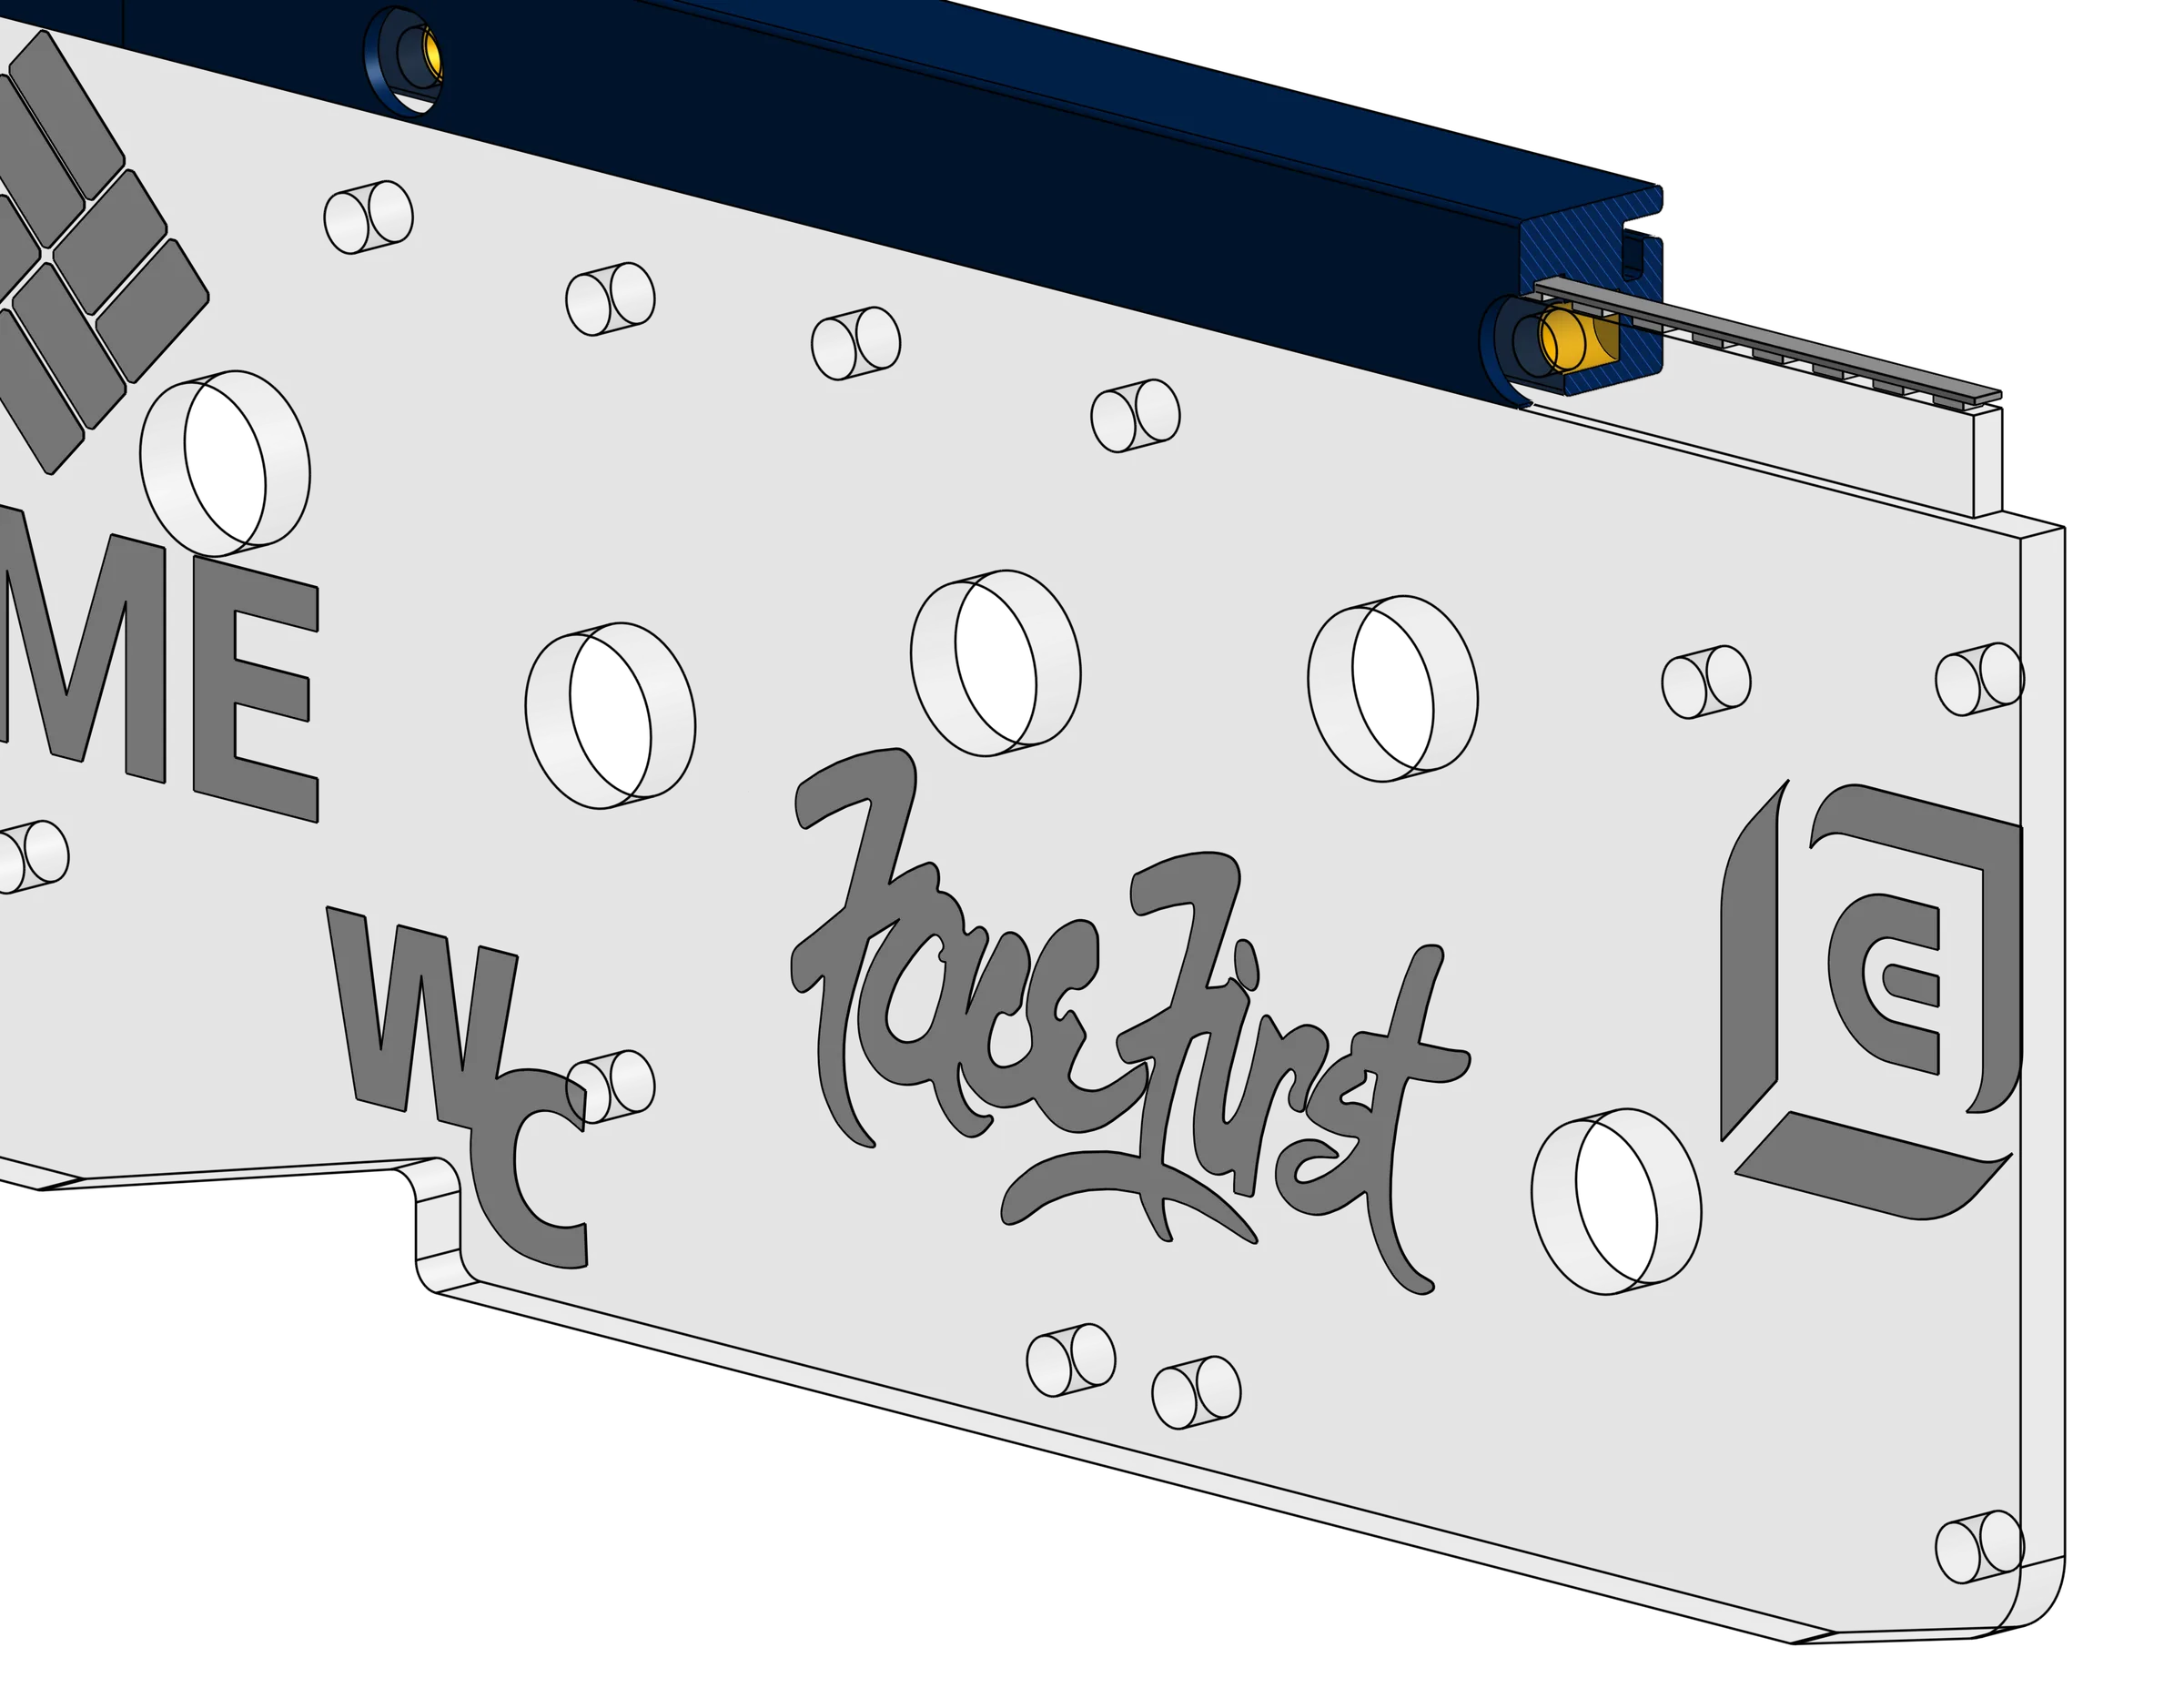
I also CADded the cases for the 2.7 mm LED strips that sat above the robot’s thin 5 mm side polycarbonate panels. To keep the cases flush with the panels’ outer surface, I redesigned the top of each panel with a machined groove. The groove sets the strip back from the edge, so the case can wrap over the lights while remaining flush.
RS-485 Sensor Network
I led a 4-person team building the communication network that links the robot’s ESP32 sensor DAQs to the VEX V5 Brain over RS-485 and Wi-Fi.
We designed and documented a binary protocol inspired by Modbus RTU, running at 10 Mbps and 6,000 packets per second. A priority packet queue with CRC-16 checks handles starvation and recurring requests, and a PlatformIO tool deploys to and monitors many ESP32s in parallel.
Each device runs up to two RS-485 (or UART) channels in parallel, plus an ESP-NOW or Wi-Fi hotspot connection. The V5 Brain tops out at 500 kbps, so it gets its own dedicated line to the master ESP32, and the DAQs chained to the master keep running at full speed.
High Stakes was my first season with the team. The game centered on scoring rings onto mobile goals and climbing a 4-foot ladder at the end of the match. We competed at the VEX World Championship and won the Build Award for our mechanical design.
Team Window Sign
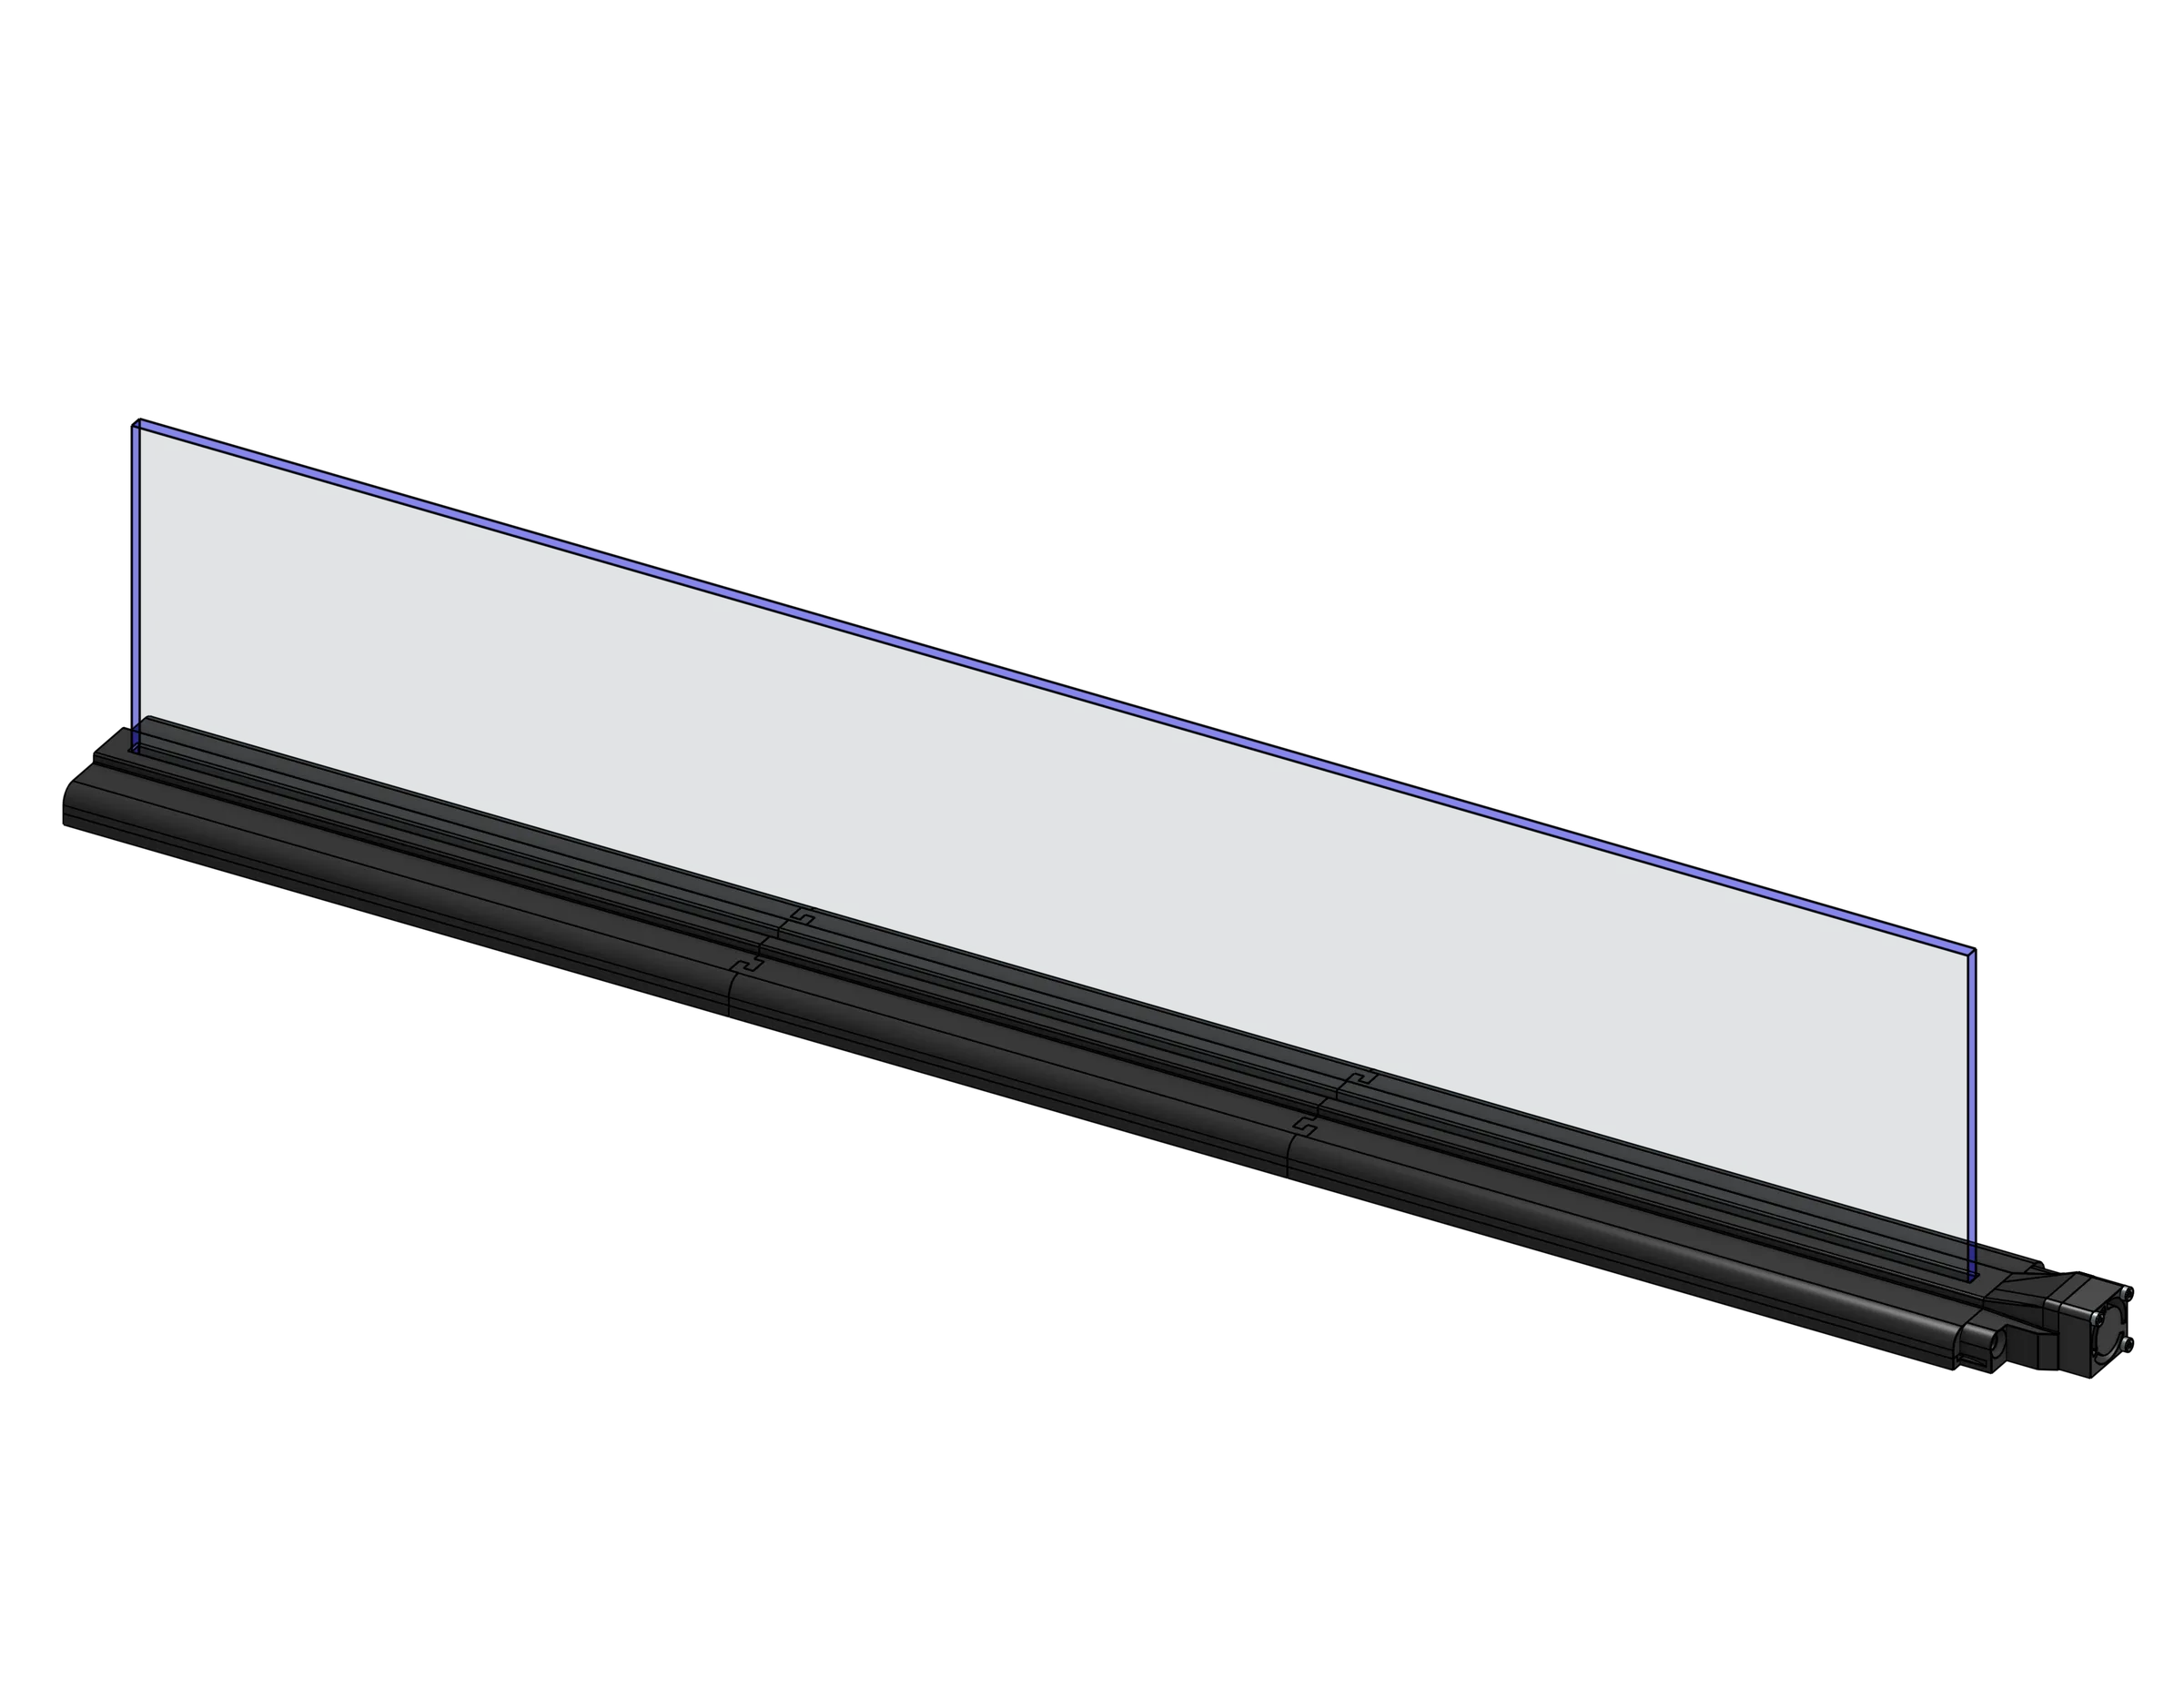
The team’s window sign is our @CBURobotics handle laser-engraved into acrylic and lit from below by an LED strip. The light spreads through the acrylic and catches on the engraving and the edges, so the lettering seems to float in a clear panel with a bright outline, like an exit sign.
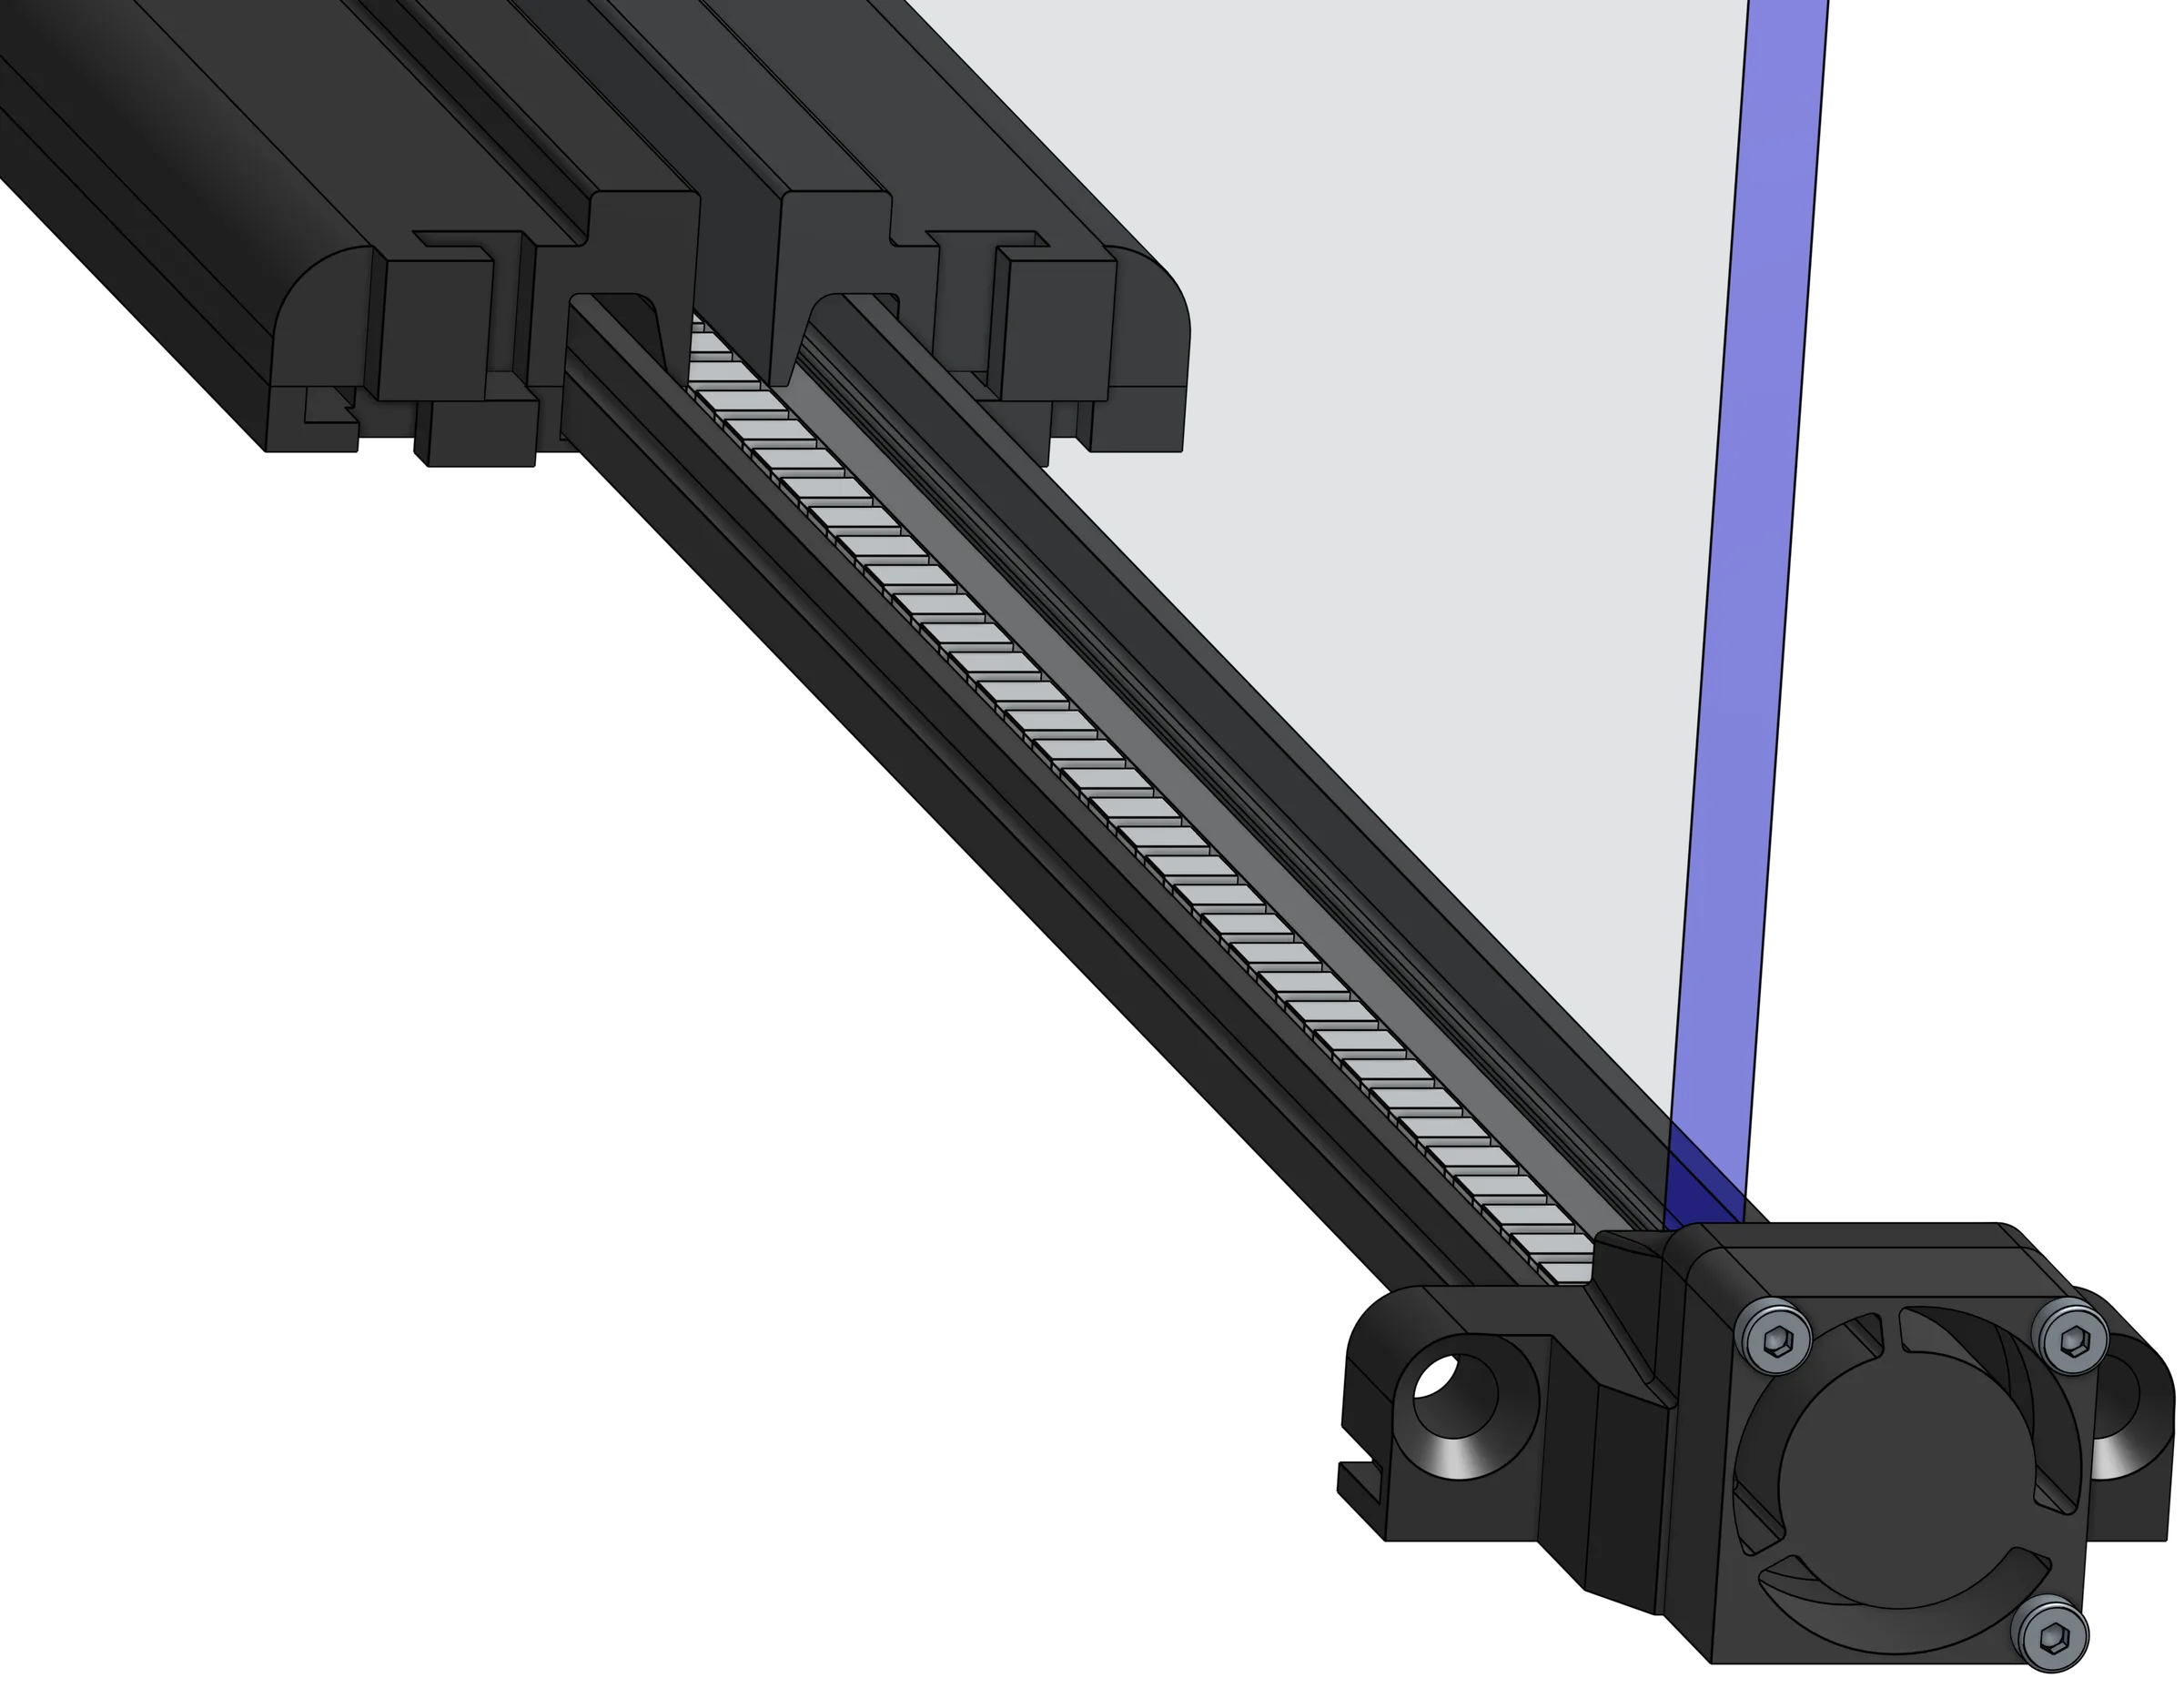
I CADded the 3D-printed base, which holds the strip on an aluminum C-channel as a heat sink. A small fan at one end blows air over the strip and the channel, through a cavity left around the strip, and out the other side. I also programmed the lights, which became the first version of the lighting engine.
Robot Lighting, V1
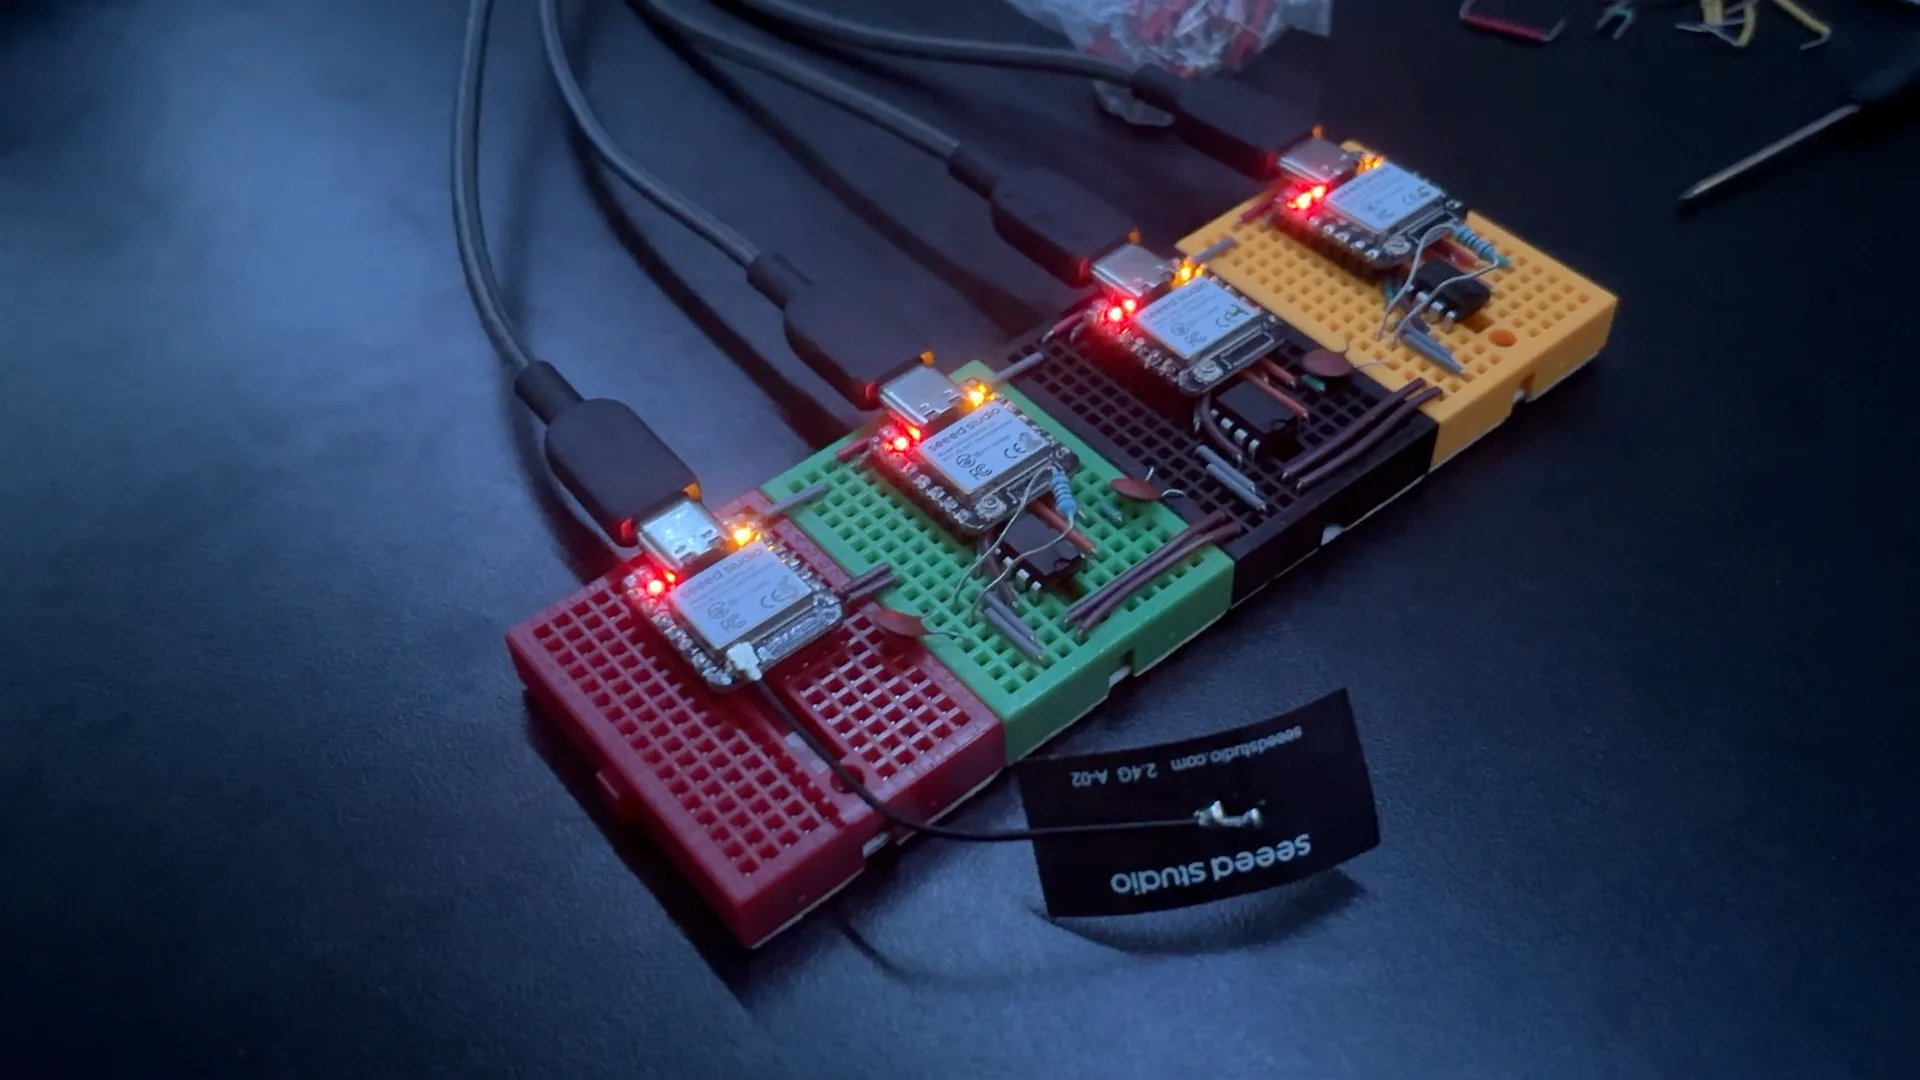
Soon after the sign, the first version of the lighting engine went onto the High Stakes robot: an Arduino Nano driving two LED strips, connected to the V5 Brain over RS-485.
The Brain sends a short status message with the match mode, the robot’s state, whether a mobile goal is clamped and whether a ring is being rejected, so the lights could give the drivers that feedback at a glance.